
Wearable Robots
Wearable Exoskeletons for Human Augmentation and Rehabilitation
We develop both enabling technologies, such as high torque density actuators and soft sensors, and complete wearable robots that augment human capability. Our exoskeletons are designed to be lightweight, compliant, and portable, so that they are comfortable to wear and assist the user effectively. We aim to make them new intervention and rehabilitation solutions for neurological and musculoskeletal disorders, such as osteoarthritis and cerebral palsy in children. Their controllers are increasingly learned in musculoskeletal simulation.
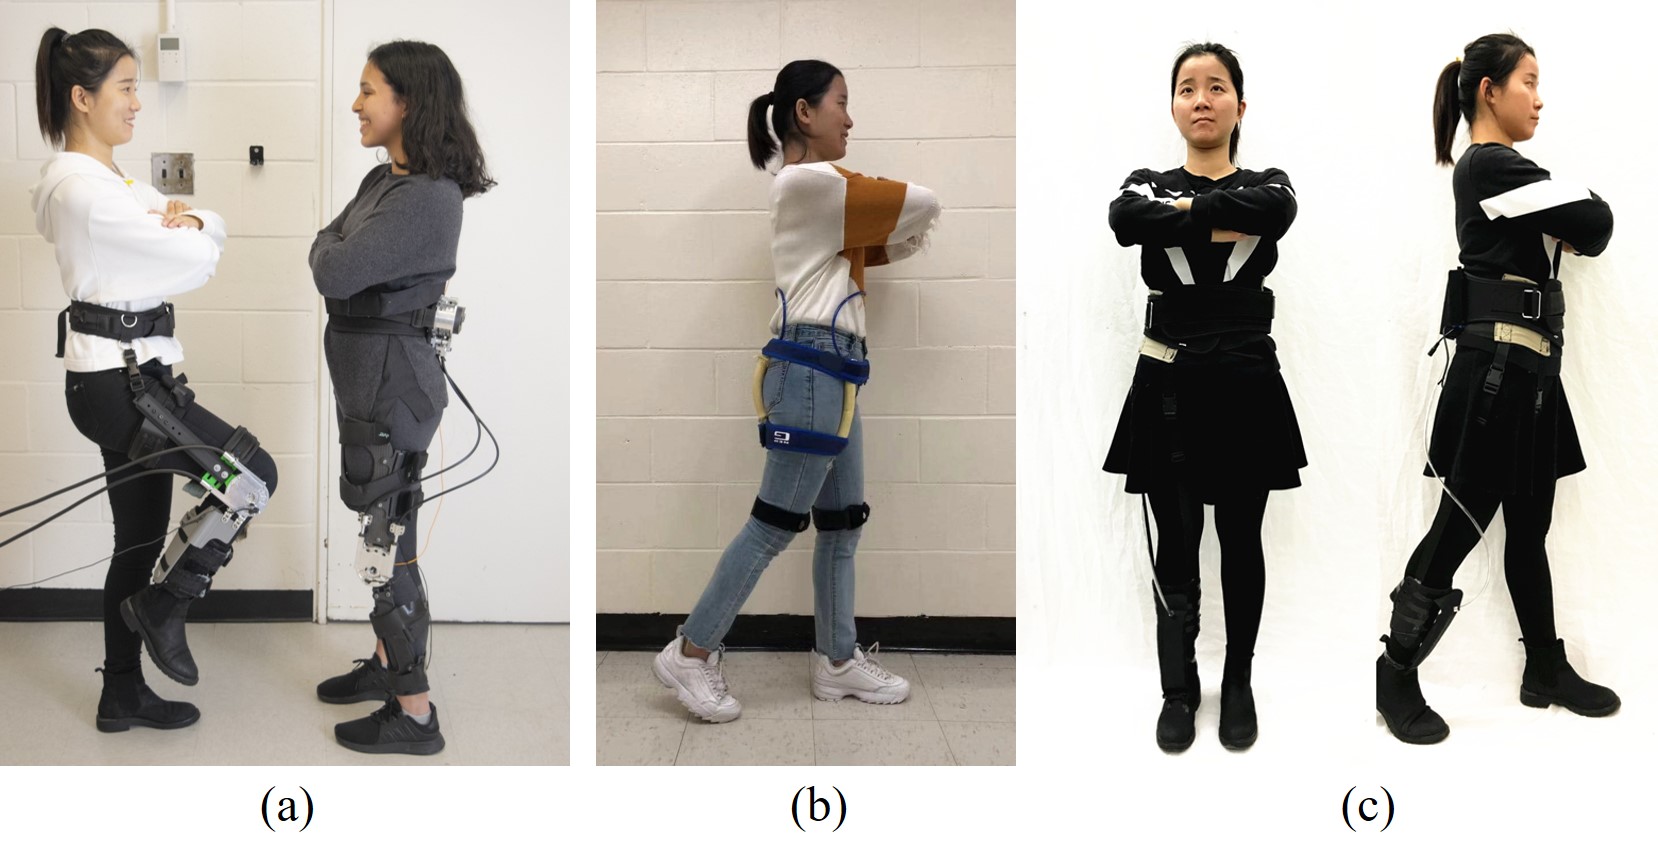
Portable and Compliant Knee Exoskeleton
Our portable knee exoskeleton weighs 3.3 kg in total and produces up to 28 Nm of peak torque. It is highly compliant, with a backdrive torque of 0.22 Nm, and assists walking, squatting, and sit-to-stand. See the knee exoskeleton page for details.
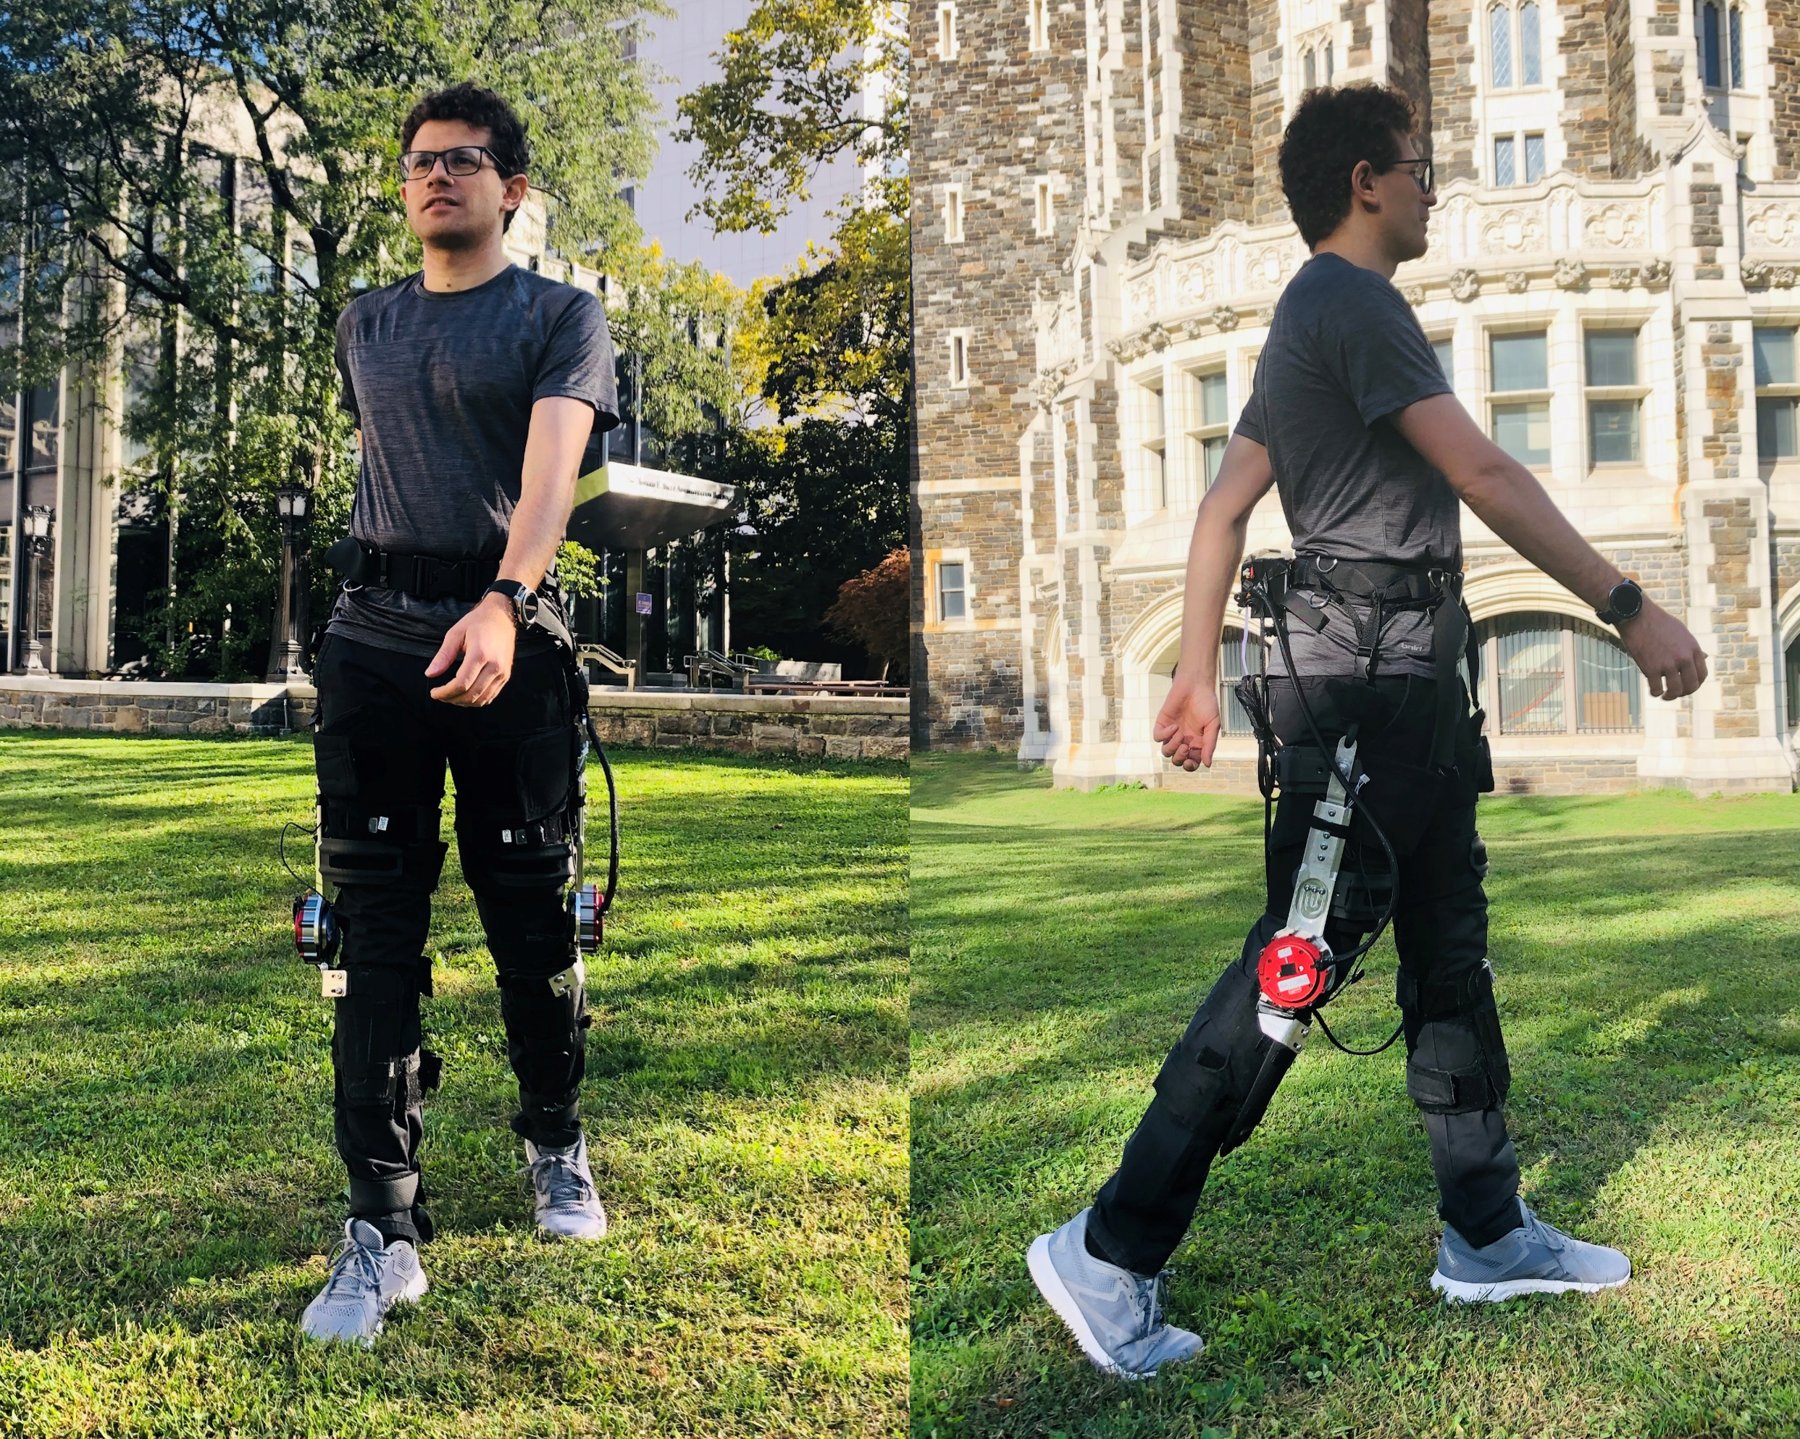
Portable and Compliant Hip Exoskeleton
Our hip exoskeleton uses quasi-direct drive actuation to combine a low mass (3.2 kg in total), compliance (backdrivability), high torque (36 Nm), and high control bandwidth. See the hip exoskeleton page for details.
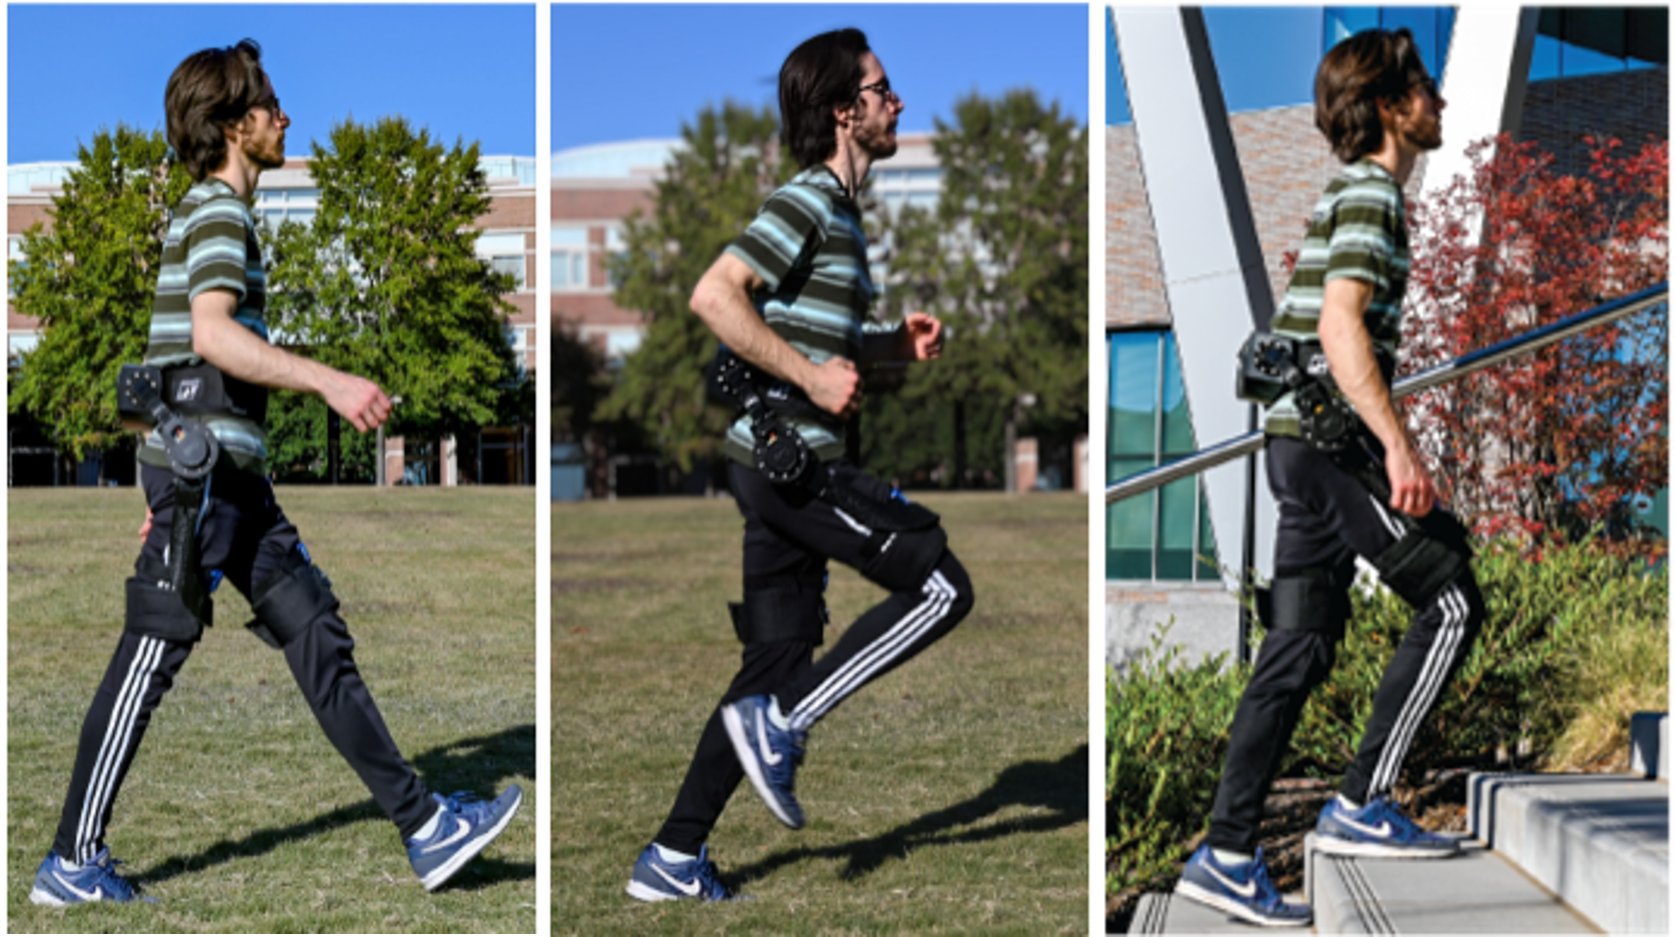
Portable and Compliant Shoulder Exoskeleton
Our portable powered shoulder exoskeleton weighs 3.3 kg in total and provides high torque assistance. It is designed for users with different levels of upper-limb impairment. See the shoulder exoskeleton page for details.

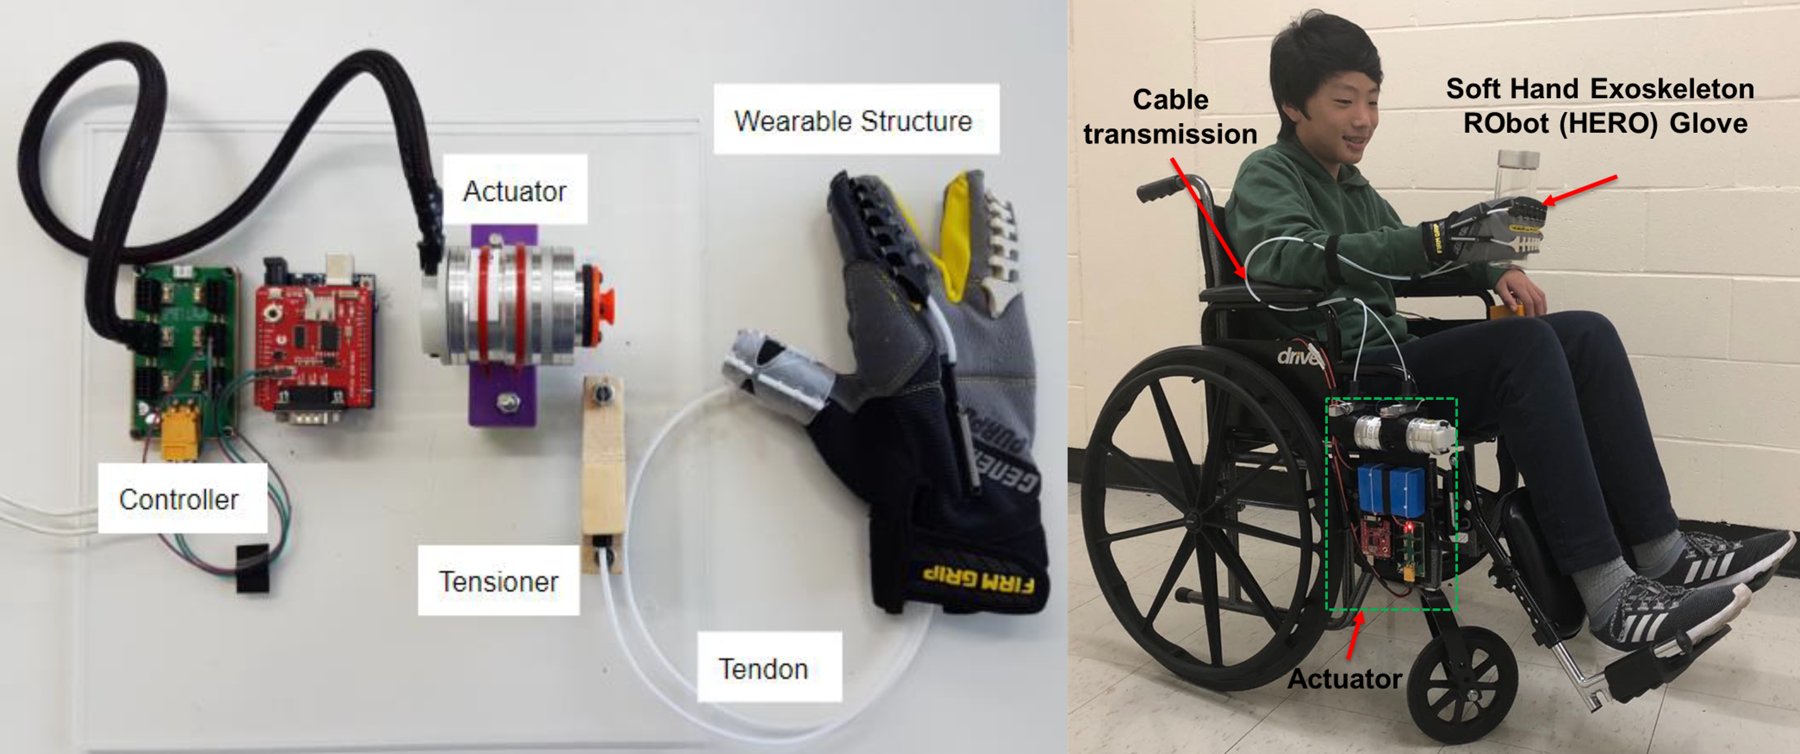
Portable Hand Exoskeleton
Our portable tendon-driven hand exoskeleton provides flexion assistance to three fingers for five classes of grasp: flat, distal, cylindrical, spherical, and ring grasps. See the hand exoskeleton page for details.
Tethered Exoskeletons for Biomechanics and Control Research
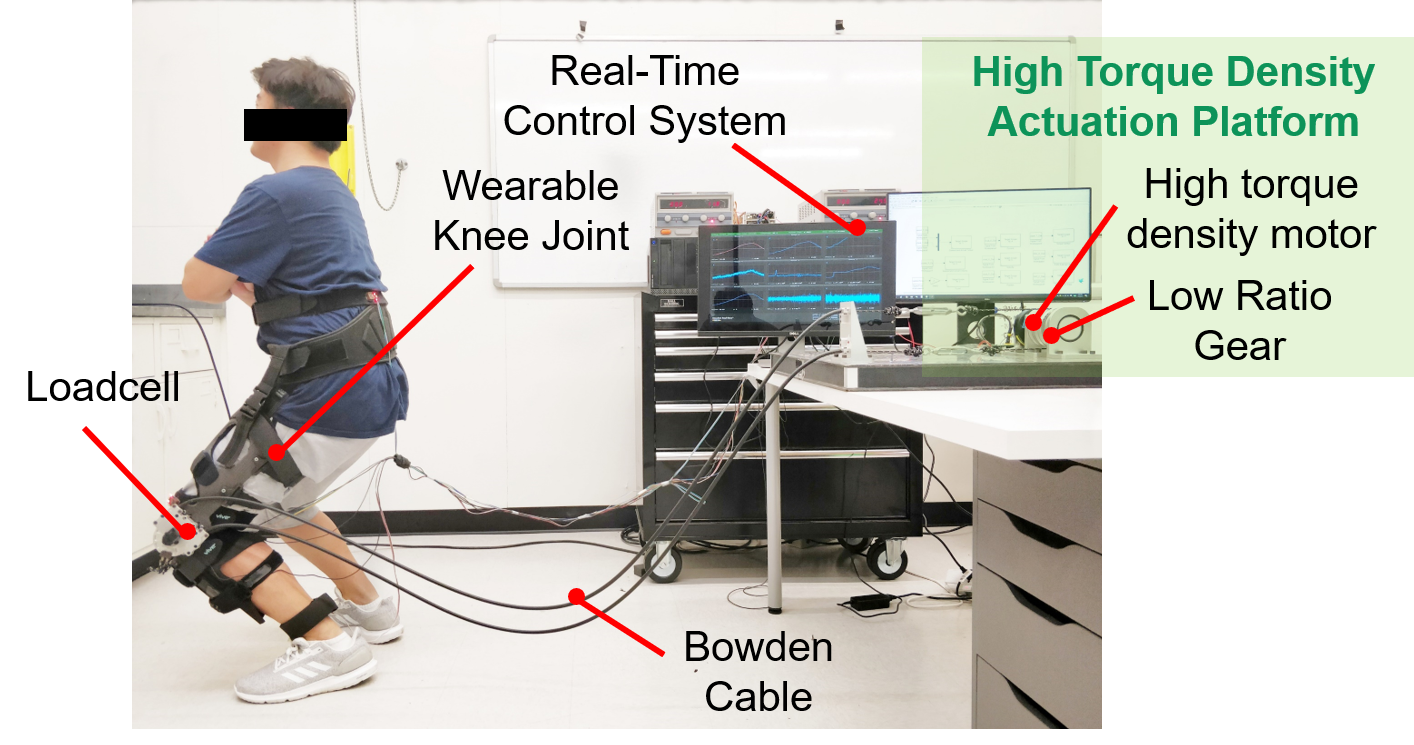
For laboratory studies of biomechanics and control, we built tethered exoskeletons whose actuation sits off the body. The tethered knee exoskeleton weighs 1 kg per side, delivers 48 or 64 Nm of nominal torque, and has a bandwidth of 65 Hz with 0.9 Nm of backdrive torque. See the tethered lower-limb exoskeleton page for details.
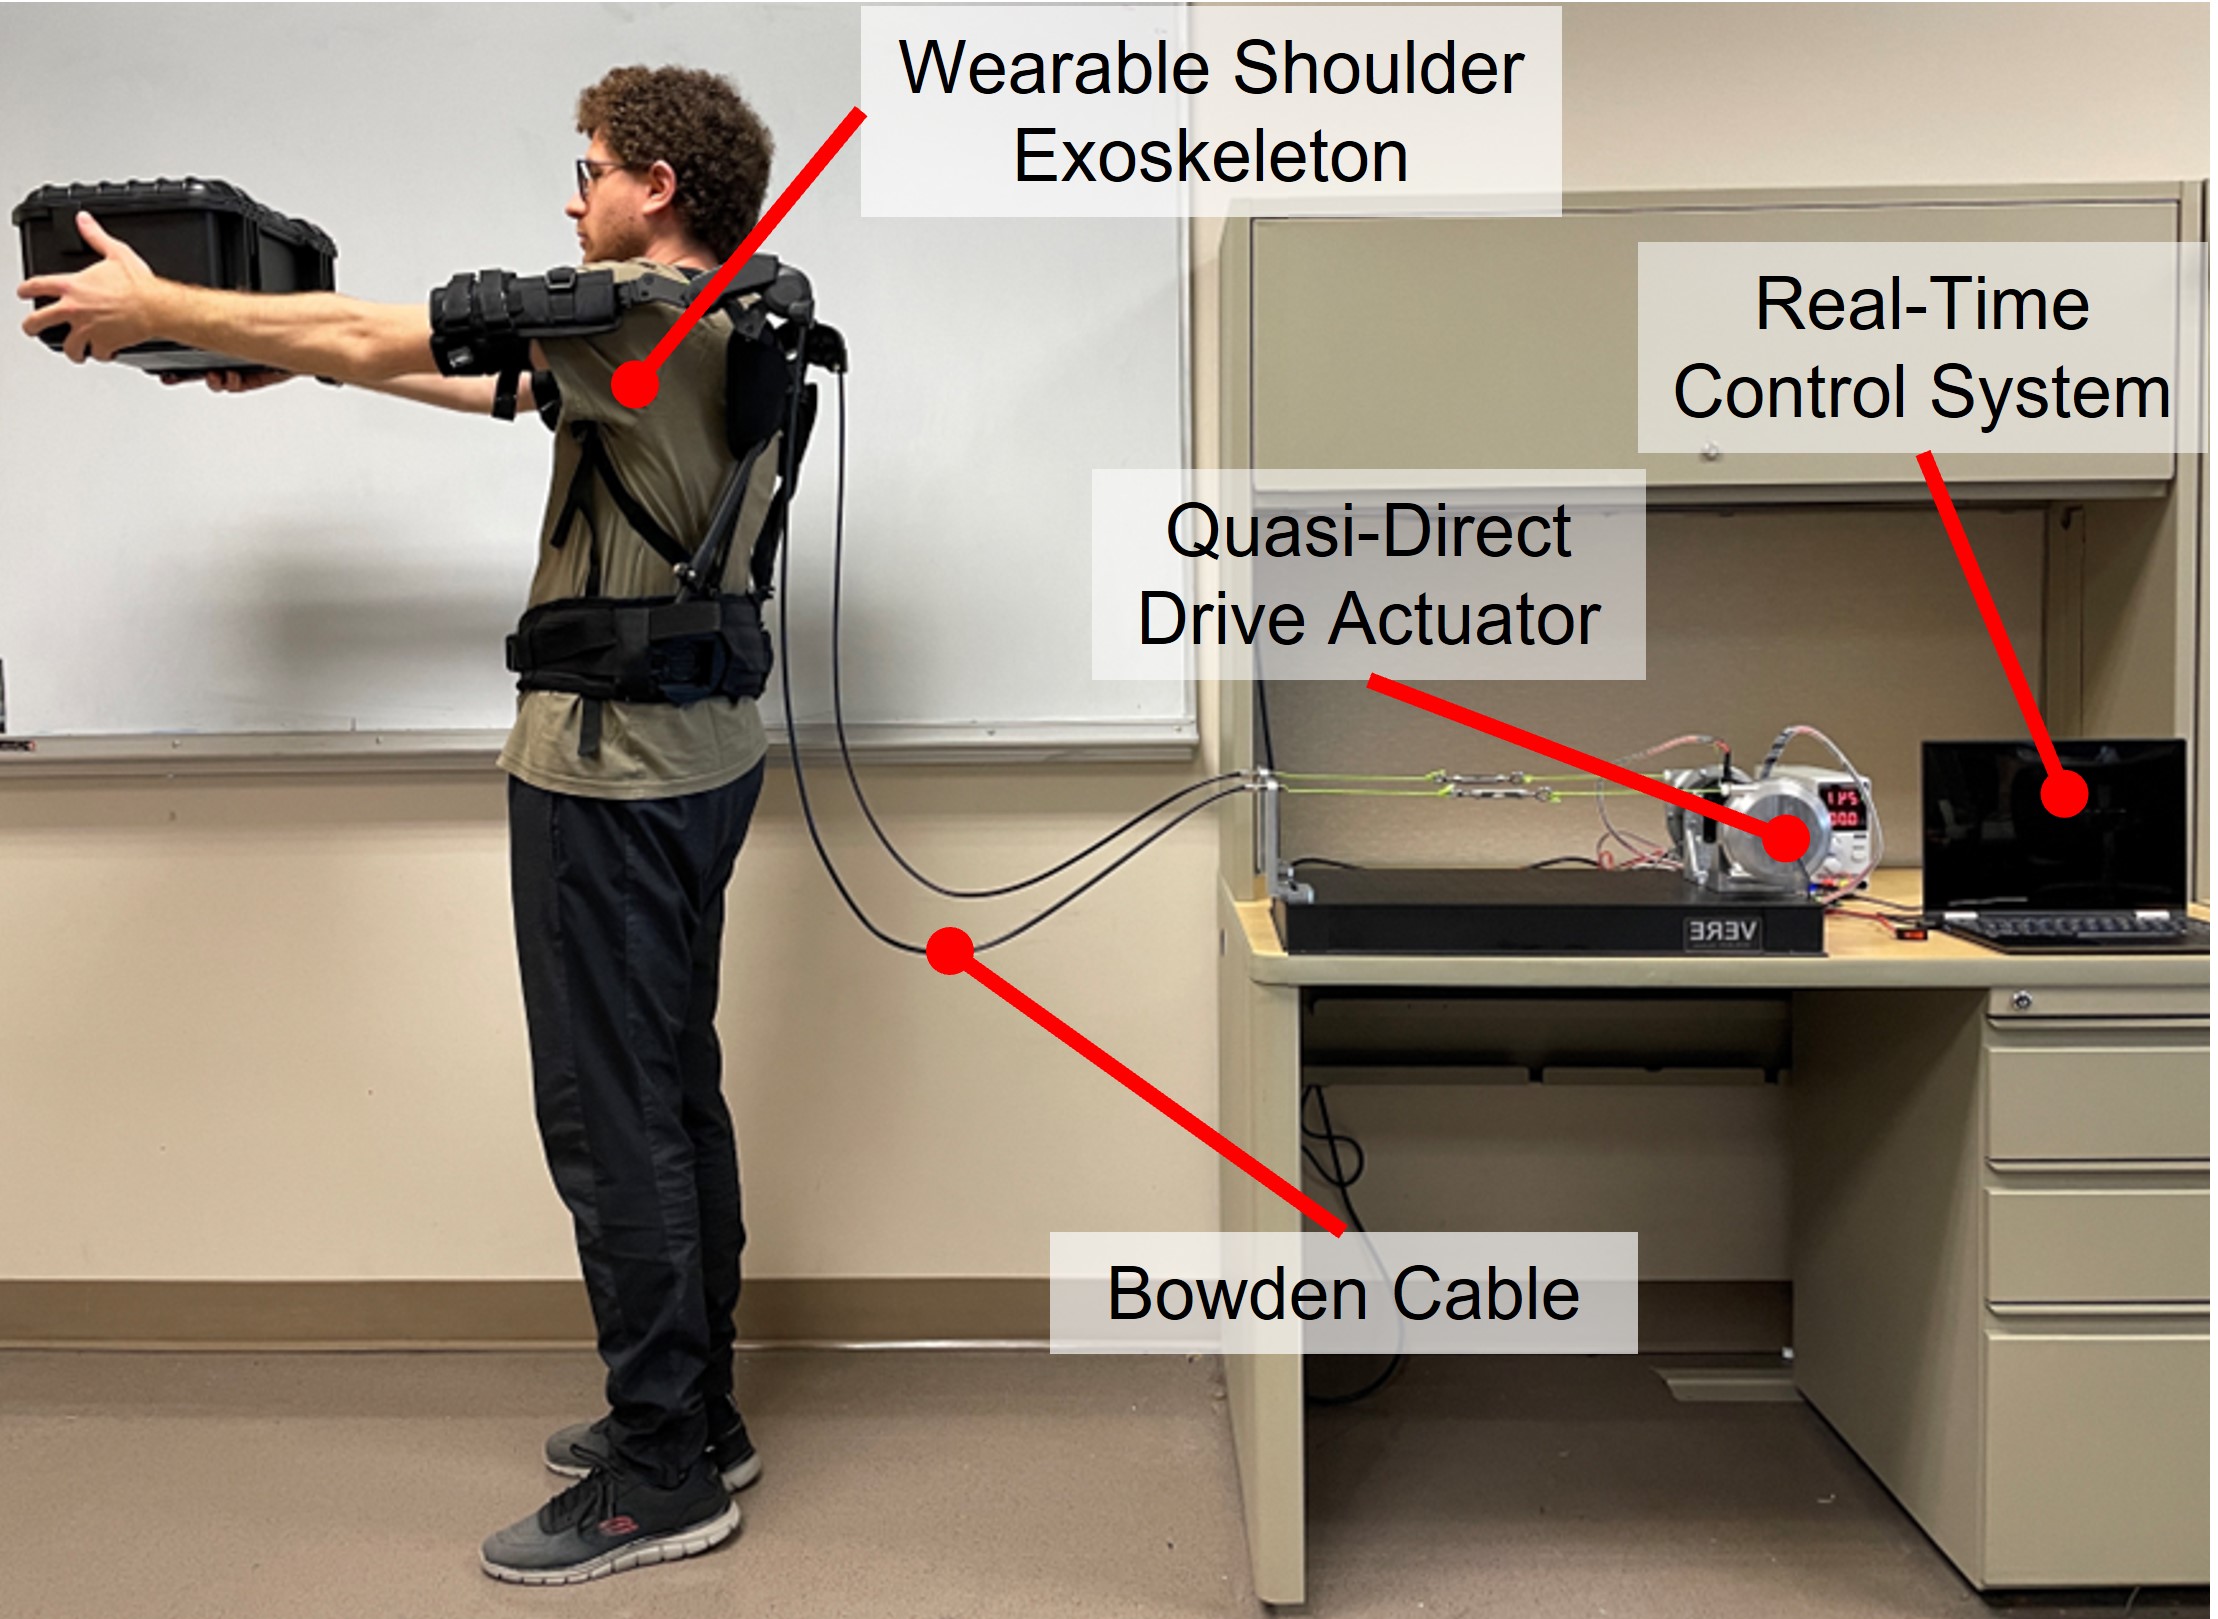
The tethered upper-limb exosuit weighs 2.2 kg without its tethered actuation and provides 13 Nm of rated and 40 Nm of peak assistive torque. See the tethered upper-limb exoskeleton page for details.
Compact and Efficient Control Electronics for Portable Robots
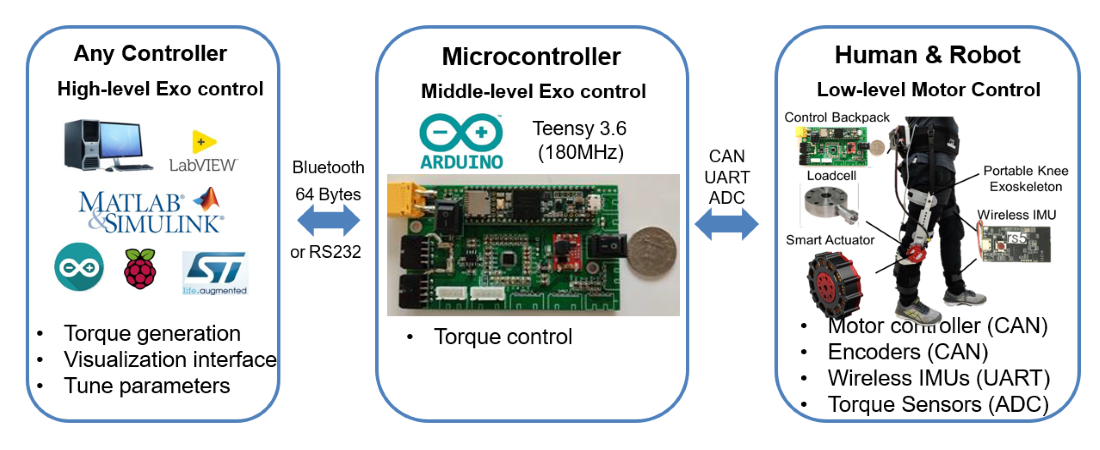
Our portable exoskeletons run on compact embedded control electronics that we design for sensing, actuator control, and communication on the robot. See the control electronics page for details.
Soft Exosuits (Postdoctoral Work at Harvard University)
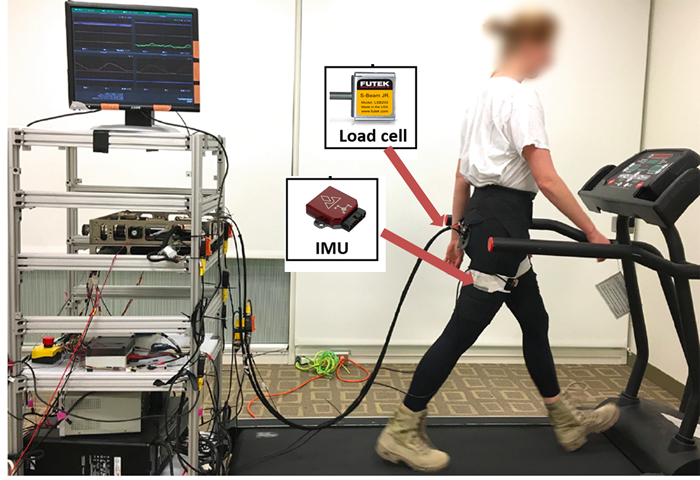
During his postdoctoral research at the Harvard Biodesign Lab, Hao Su developed wearable sensors for human motion sensing and a force control system on a 4-DOF offboard actuation platform. Compared with a conventional rigid exoskeleton, the textile-based soft exosuit has several advantages: the worn part of the suit is very light, it avoids misalignment between the biological and robot joints, and it minimizes unintended interference with the wearer’s natural biomechanics, allowing more synergistic interaction with the wearer. The project was led by Prof. Conor Walsh and involved multidisciplinary researchers in apparel design, biomechanics, and robotics.
Gait Rehabilitation System for Children with Developmental Delays (Postdoctoral Work at Harvard University)
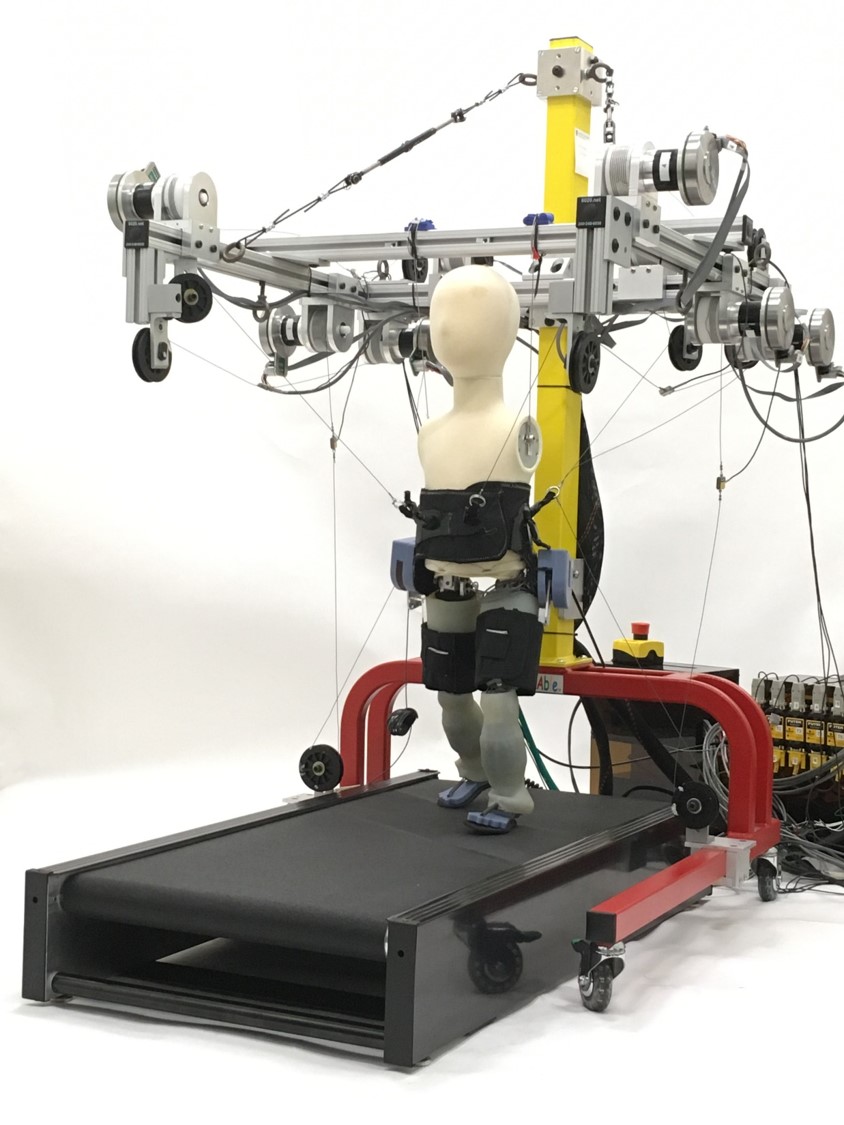
Hao Su also contributed to the control system of a modular, computationally distributed multi-robot cyber-physical system (CPS) for gait rehabilitation of children with developmental delays. The system combines two robots: a multi-cable scaffold robot that continuously modulates the stabilization of medio-lateral and anterior-posterior sway, and a soft, wearable exosuit with embedded sensing and actuation that assists stance push-off and swing flexion. His role was to develop an IMU-based gait detection and control strategy that assists and coordinates pelvic motion and hip flexion, and adapts to different subjects and gaits. The PI was Prof. Eugene Goldfield (Boston Children’s Hospital, Harvard Medical School), with co-PIs Prof. Conor Walsh and Prof. Sunil Agrawal (Columbia University).
Key Publications
- S. Luo, M. Jiang, S. Zhang, J. Zhu, S. Yu, I. Dominguez Silva, T. Wang, E. Rouse, B. Zhou, H. Yuk, X. Zhou, and H. Su, “Experiment-free exoskeleton assistance via learning in simulation,” Nature, vol. 630, no. 8016, pp. 353–359, Jun. 2024. [PDF] [Supplementary Materials] [Editor Perspective]
- J. Zhou, W. Gao, J. S. Huang, K. Lin, W. Wu, and H. Su, “PositiveAssist: Energy-Gated Control for Positive Power Assistance of Exoskeleton in Walking, Running, and Stair Climbing,” IEEE/ASME Transactions on Mechatronics, 2026. [PDF] [Video]
- Y. Yan, J. S. Huang, J. Zhu, Z. Hou, W. Gao, I. Lopez-Sanchez, N. Srinivasan, A. Srihari, and H. Su "Compact and Foldable Hip Exoskeleton With High Torque Density Actuator for Walking and Stair-Climbing Assistance in Young and Older Adults," in IEEE/ASME Transactions on Mechatronics, 2025. [PDF] [Video]
- D. Rodriguez-Jorge, S. Zhang, J. S. Huang, I. Lopez-Sanchez, N. Srinivasan, Q. Zhang, X. Zhou, and H. Su, “Biomechanics-Informed Mechatronics Design of Comfort-centered Portable Hip Exoskeleton: Actuator, Wearable Interface, Controller,” IEEE Transactions on Medical Robotics and Bionics, 2025. [PDF]
- S. Yu, T.H Huang, X. Yang, C. Jiao, J. Yang, Y. Chen, J. Yi, H. Su. "Quasi-Direct Drive Actuation for a Lightweight Hip Exoskeleton with High Backdrivability and High Bandwidth", IEEE/ASME Transactions on Mechatronics. vol. 25, no. 4, pp. 1794-1802, Aug. 2020. [PDF] [Presentation Video] [Short Demo Video]
- T. Huang*, S. Zhang*, S. Yu, M. MacLean, J. Zhu, A. Lallo, C. Jia, T. Bulea, M. Zheng and H. Su, "Modeling and Stiffness-Based Continuous Torque Control of Lightweight Quasi-Direct-Drive Knee Exoskeletons for Versatile Walking Assistance," in IEEE Transactions on Robotics (TRO), vol. 38, no. 3, pp. 1442-1459, Jun. 2022. [PDF] [Video]
- S. Zhang, J. Zhu, T.H. Huang, S. Yu, J. S. Huang, I. Lopez-Sanchez, T. Devine, M. Abdelhady, M. Zheng, T. C. Bulea, and H. Su, “Actuator optimization and deep learning-based control of pediatric knee exoskeleton for community-based mobility assistance,” Mechatronics, vol. 97, p. 103109, Feb. 2024. [PDF] [Video]
See all publications.