
Portable Lightweight and Compliant Knee Exoskeleton
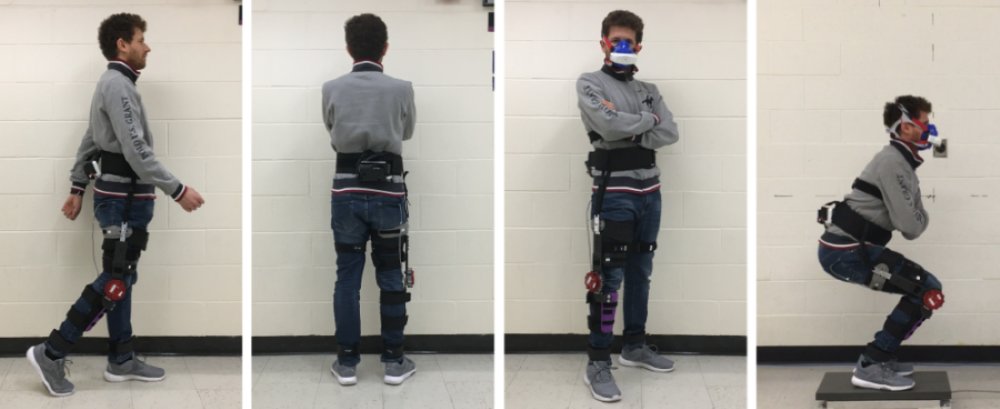
Specifications
| Property | Value |
|---|---|
| Unilateral Mass | 1.33 kg |
| Bilateral Mass (including battery, electronics) |
3.3 kg |
| Voltage | 24 V |
| Continuous Torque | 9 Nm |
| Speed | 170 RPM |
| Peak Output Torque | 27 Nm |
| Gear Ratio | 9:1 |
| Range of Motion | 0 - 160 degrees |
| Battery Life | 2 hours |
| Wearable Structures | Small. Middle, Large |
| Actuation Type | Portable |
Portable Exoskeleton Architecture
.png)
Video
Our Portable Knee Exoskeleton

Our Tethered Knee Actuation Platform

Related Publication
- S. Yu, J. Yang, T. Huang, J. Zhu, C. Visco, F. Hameed, J. Stein, X. Zhou and H. Su,
“Artificial Neural Network-Based Activities Classification, Gait Phase Estimation, and Prediction” in Annals of Biomedical Engineering, 2023.
 PDF
- S. Yu, T.H. Huang, A. Di Lallo, S. Zhang, T. Wang, Q. Fu, and H. Su "Bio-Inspired Design of a Self-Aligning, Lightweight, and Highly-Compliant Cable-Driven Knee Exoskeleton"
Frontiers in Human Neuroscience. p.763. Nov. 2022.
PDF
- T. Huang*, S. Zhang*, S. Yu, M. MacLean, J. Zhu, A. Lallo, C. Jia, T. Bulea, M. Zheng
and H. Su, " "Modeling and Stiffness-Based Continuous Torque Control of Lightweight Quasi-Direct-Drive Knee Exoskeletons for Versatile Walking Assistance,"
in IEEE Transactions on Robotics, vol. 38, no. 3, pp. 1442-1459, Jun. 2022.
PDF
| Video
- S. Luo, G. Androwis, S. Adamovich, H. Su, E. Nunez and X. Zhou. "Reinforcement Learning and Control of a Lower Extremity Exoskeleton for Squat Assistance." Frontier Robotics & AI 8:702845. 2021
PDF
- S. Chen, D.T. Stevenson, S. Yu, M. Mioskowska, J. Yi, H. Su, M. Trkov, "Wearable Knee Assistive Devices for Kneeling Tasks in Construction," in IEEE/ASME Transactions on Mechatronics, vol. 26, no. 4, pp. 1989-1996, Aug. 2021.
PDF
- J. Wang, X. Li, T. Huang, S. Yu, Y. Li, T. Chen, A. Carriero, M. Oh-Park, H. Su,
“Comfort-Centered Design of a Lightweight and Backdrivable Knee Exoskeleton”,
IEEE Robotics and Automation Letters, vol. 3, no. 4, pp. 4265-4272, Oct. 2018
PDF
| Video
| Code