
Research
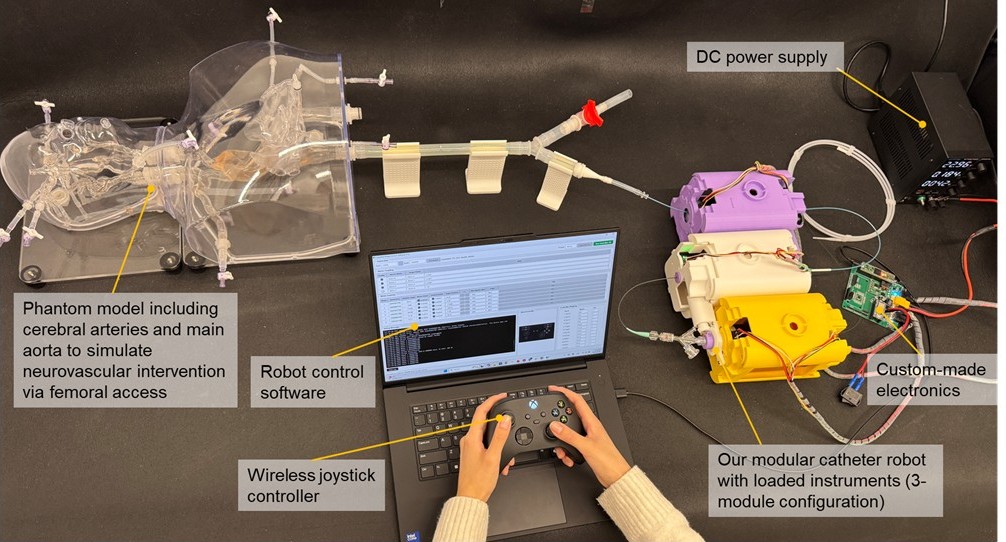
Surgical Robots
Compact, modular robots for endovascular interventions, endoscopic neurosurgery, and urology, with autonomous skills learned in simulation.
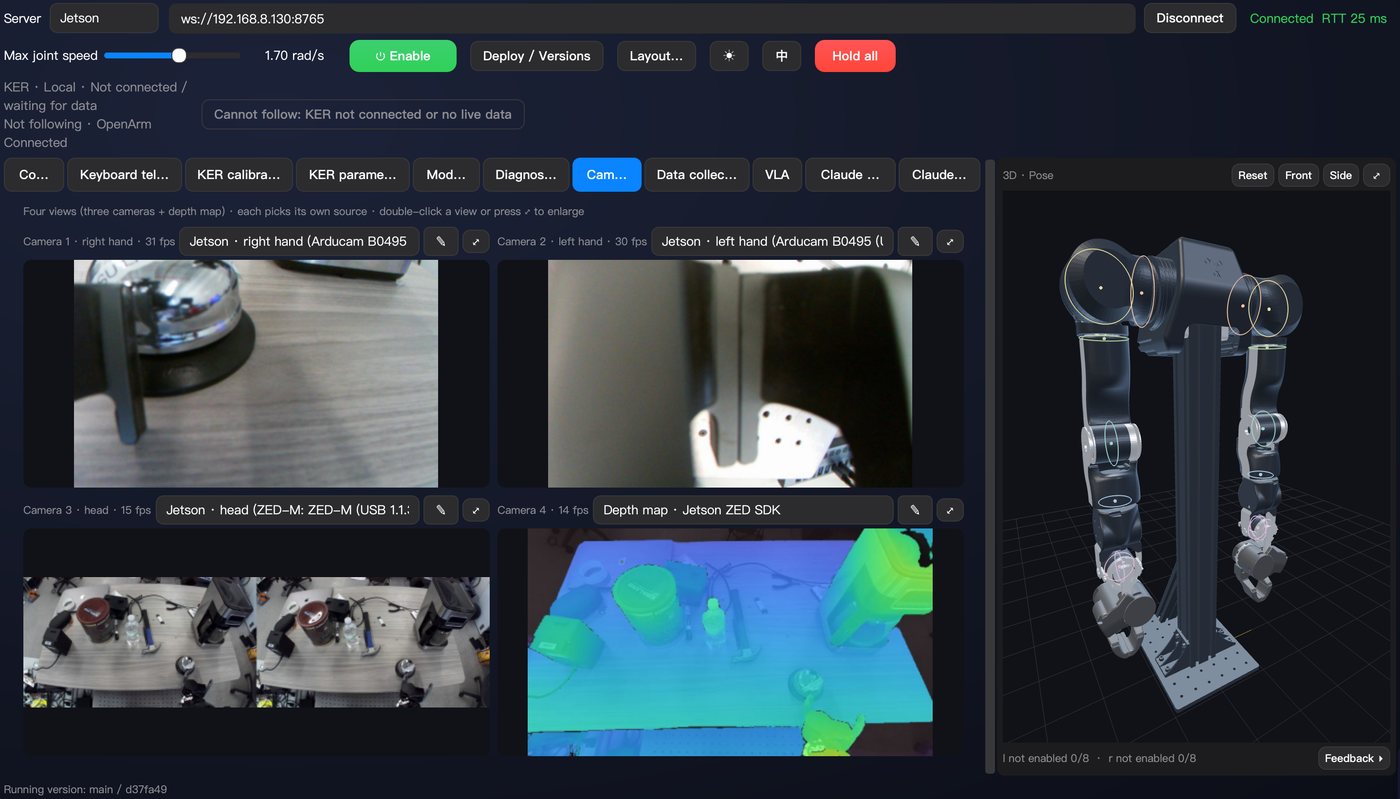
Dexterous Manipulation and Humanoid Robots
Agentic bimanual robots for long-horizon, contact-rich tasks, and humanoid locomotion control.
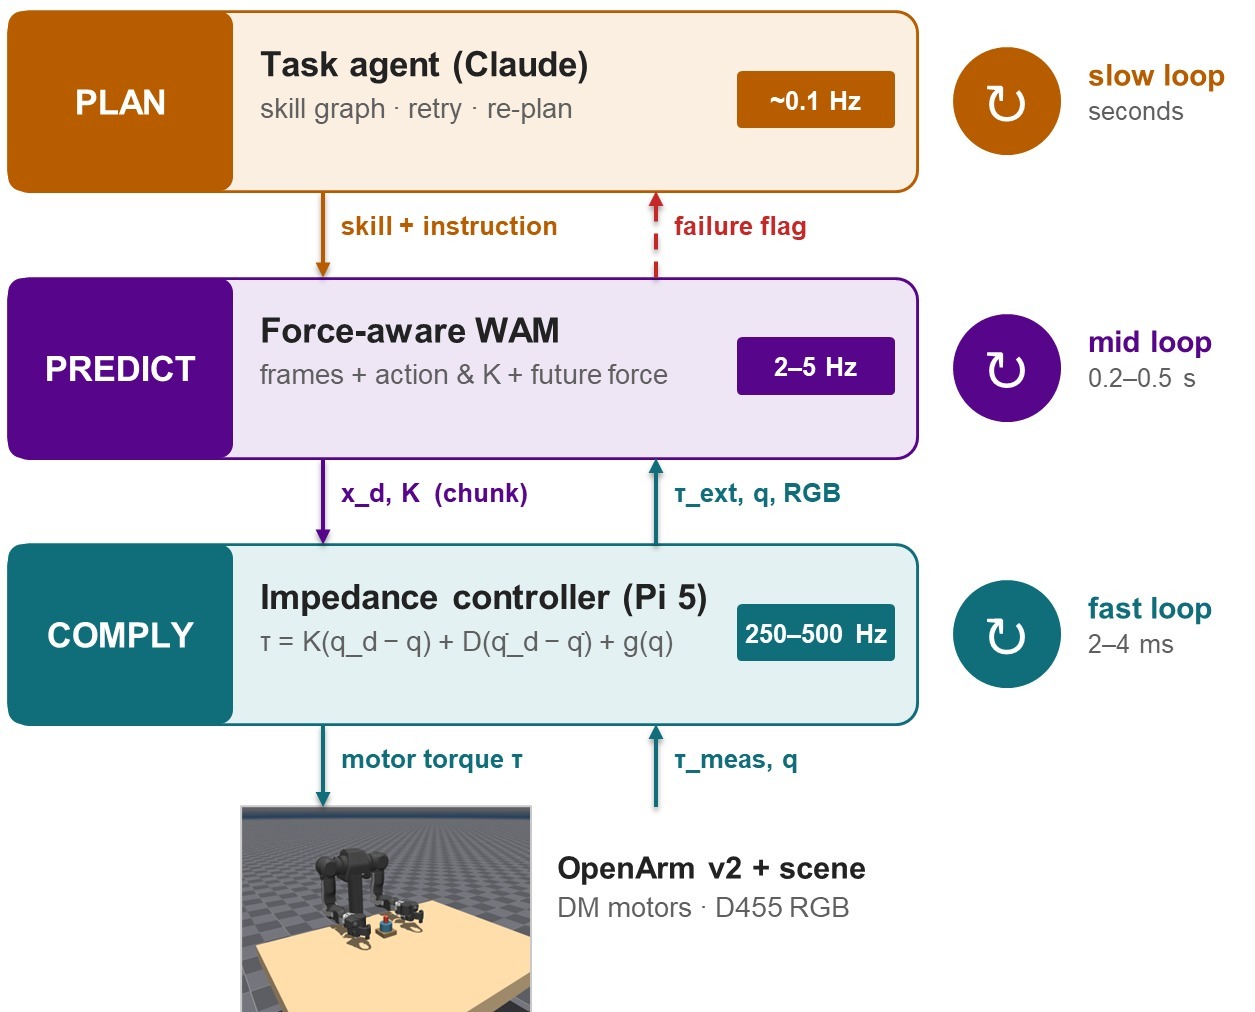
World Models
Force-aware world models that predict the outcome of contact before acting, for manipulation and neurovascular intervention.
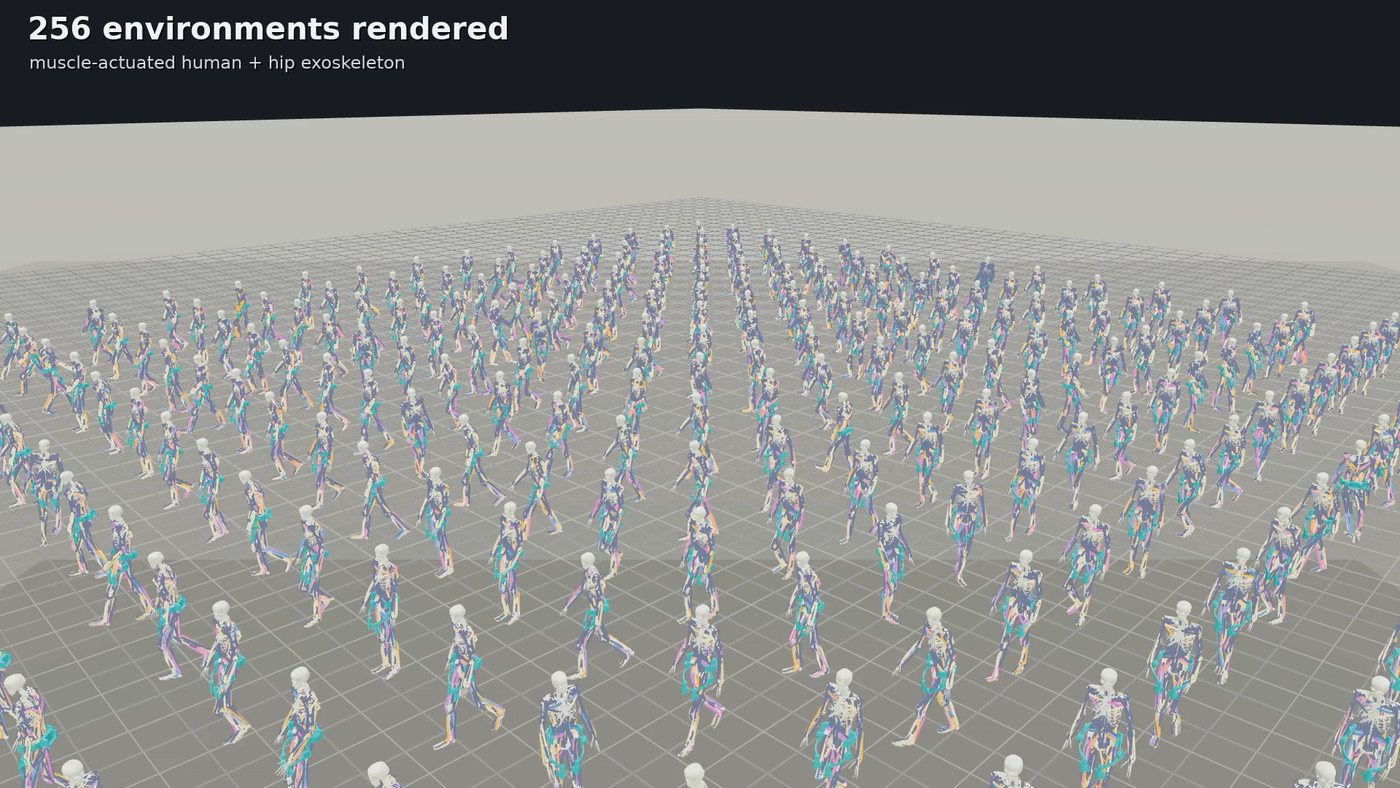
Reinforcement Learning
Physics-informed reinforcement learning in large-scale simulation, transferred to real exoskeletons.
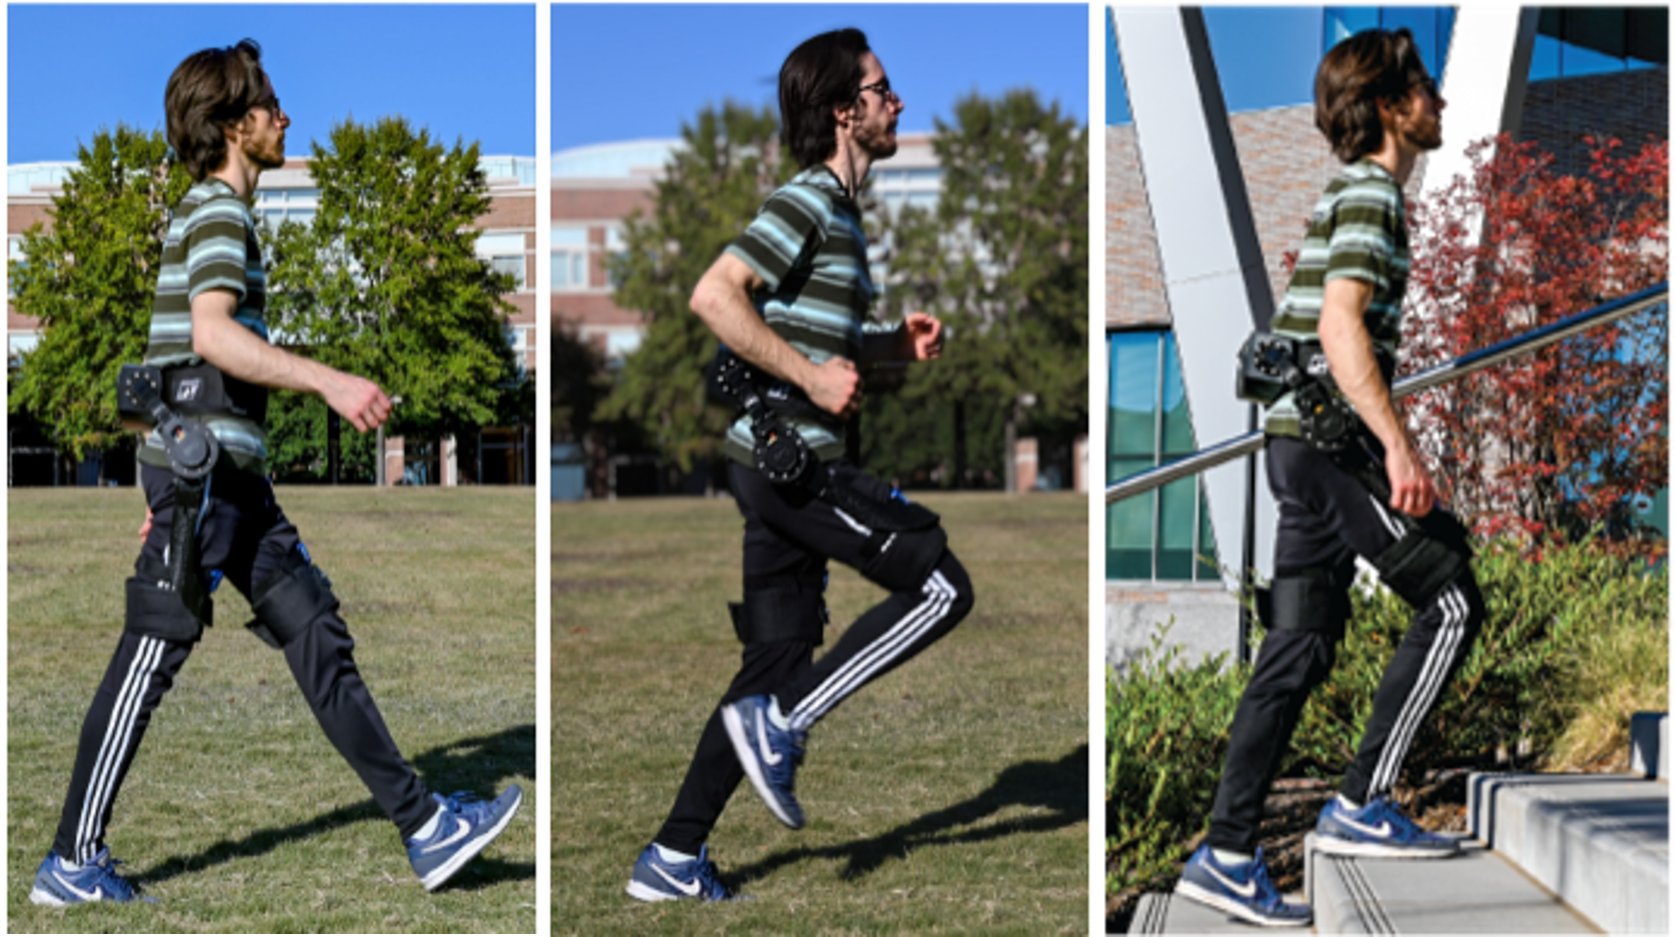
Wearable Robots
Portable hip, knee, and shoulder exoskeletons that reduce the energy cost of walking, running, and stair climbing.
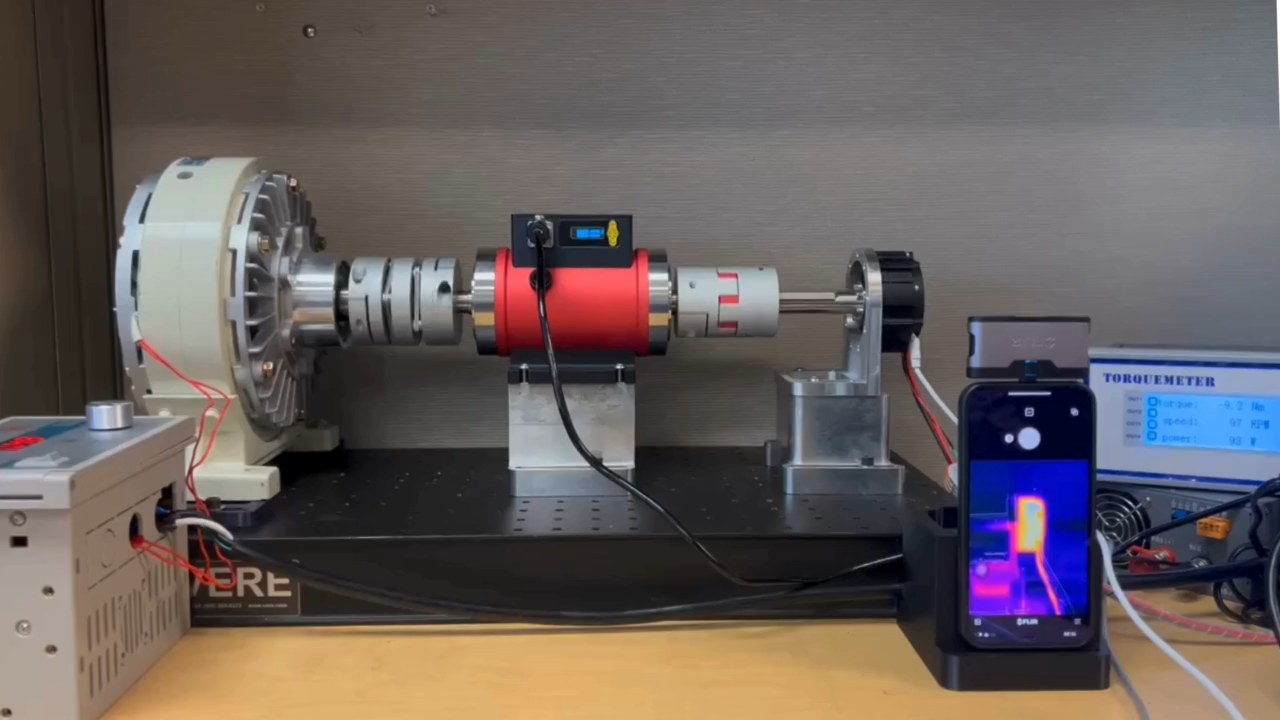
Actuators and Sensors
High torque density actuators with FEM simulation, thermal modeling, and thermal-aware control.

Soft Robots
Fabric exosuits, electro-hydraulic actuators, and soft sensors for high-force wearable assistance.