Biomechatronics and Intelligent Robotics Lab
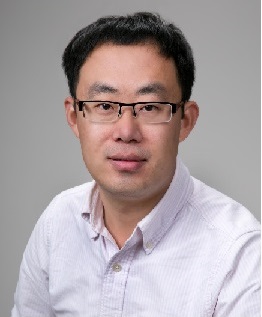
Dr. Hao Su, PhD, is an Associate Professor at the New York University.
He is the Director of Biomechatronics and Intelligent Robotics Lab.
He was an associate professor at North Carolina State University and the University of North Carolina at Chapel Hill,
after previously serving as the Irwin Zahn Endowed Assistant Professor at City College of the City University of New York.
He was a Research
Scientist at Philips Research North America where he designed robots for lung surgery,
and then a postdoctoral fellow at Harvard University and Wyss Institute for Biologically Inspired
Engineering.
He obtained Ph.D. degree on Surgical Robotics at Worcester Polytechnic Institute. Dr. Su received
NSF CAREER Award,
Switzer Distinguished Fellow by U.S. Department of Health and Human Services, Toyota Mobility Challenge Discover
Award, the Best Medical Robotics Paper Runner-up Award in IEEE International Conference on Robotics and Automation (ICRA),
Best Student Paper Award, Dynamic Systems & Control Division, American Society of Mechanical Engineers, and Philips Innovation
Transfer Award. He received the Advanced
Simulation & Training Award from the Link Foundation and Dr. Richard Schlesinger Award
from the American Society for Quality. His work was published in IEEE Transactions on Robotics, IEEE/ASME
Transactions on Mechatronics, Nature, Science Robotics, Nature Machine Intelligence, Nature Communications,
and Science Advances. He serves as Technical Editor of
IEEE/ASME Transactions on Mechatronics, associate editor of IEEE Robotics and Automation Magazine (RAM), IEEE Robotics and Automation Letters (RAL), IEEE International Conference
on Robotics and Automation (ICRA), IEEE/RSJ International
Conference on Intelligent Robots and Systems (IROS), and serves on the Editorial Advisory Board for
the International Journal of Medical Robotics and
Computer-Assisted Surgery. He is a keynote speaker of IEEE/RSJ International
Conference on Intelligent Robots and Systems (IROS).
In addition, Dr. Su is the Chair of the Mechatronics Technical Committee, Dynamic Systems &
Control Division, American Society of Mechanical Engineers (ASME), and the Co-Chair of the Technical
Committee on Mechanisms and Design, IEEE Robotics and Automation Society (RAS). He is a member of the
Organizing Committee and Senior Program Committee of IROS 2026.
Dr. Su is reviewer of NIH Bioengineering, Technology and Surgical Sciences Study Section (BTSS) and NIH Musculoskeletal Rehabilitation Sciences Study Section (MRS). He holds patents on surgical
robotics and socially assistive robots.
 Weibo Gao
 Jason Huang
 Juncheng Zhou
 Shutong Zhong
 Bowen Zheng
 Qianhe Fan
 Sreenidhi Kamalam
 Prithvijeet Saha
Manufacturing Engineer, P&G
New York University
NC State University
NC State University
NC State University
Duke University
NC State University
NC State University
 Dr. Ivan Lopez-Sanchez
 Dr. Junxi Zhu
 Dr. Israel Dominguez Silva
 Dr. Menghan Jiang
 Nitin Srinivasan
 Dr. Sainan Zhang
 Dr. Yuming Yan
 Dr. Zhimin Hou
 Dr. Daniel Rodriguez-Jorge
 Thomas H. Taylor
 Dr. Shuzhen Luo
 Dr. Shuangyue Yu
 Dr. Tzu-hao Huang
 Dr. Tairan Liu
 Dr. Thassyo Pinto
 Dr. Mhairi MacLean
 Dr. Lin Jiang
 Dr. Fangshi Zhu
 Hadia Perez
 Jade Ardinez
 Brian Lynn
 Kevin Nogacz
 Jason Calle
 Antony John E
 Haixiang (Nick) Fang
 Benjamin Bokser
Fangshi Zhu, Co-advised with Dr. James Chang, currently at Apple
Tzu-Hao Huang, Postdoc fellow, currently Assistant Professor at City University of New York
Xiaolong Yang, Postdoc fellow, currently Associate Professor
Ben Bokser, Engineer, Boeing
Valentin Adesman, Engineer, Raytheon
Yanjun Li, PhD Candidate, Case Western Reserve University
Jiaqi Guo, PhD Candidate, New York University
Junlin Wang, Mechanical Engineer, BrianCo Inc., M.S., Carnegie Mellon University
Xiao Li, Mechanical Engineer, BrianCo Inc., M.S., Virginia Tech
Haodan Tan, Intern, United Nations, Ph.D., Indiana University
Yuxin Fu, Research Scholars, M.S., Columbia University
Jianfu Yang, Research Scholars, M.S., Columbia University
Jiechao Ma, Research Scholars, Ph.D., Purdue University
Yuxin Fu, Apple Inc., M.S. Columbia University