
Reinforcement Learning
Simulation to Reality: Learning Multi-gait Exoskeleton Control for Mobility Assistance via Musculoskeletal Modeling
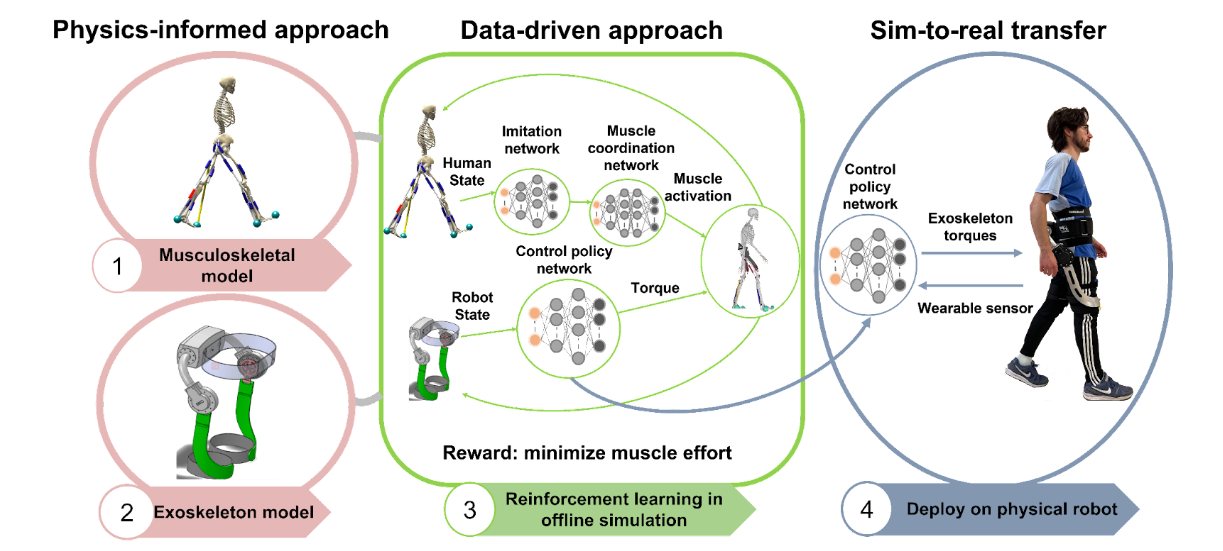
We demonstrate the feasibility of developing control strategies for hip exoskeleton entirely in simulation via reinforcement learning. We created a data-driven and physics-informed approach that leverages reinforcement learning in concert with a musculoskeletal model to automatically learn a robot controller entirely in simulation. This work was published in Nature (2024).
Large-Scale Parallel Musculoskeletal Simulation
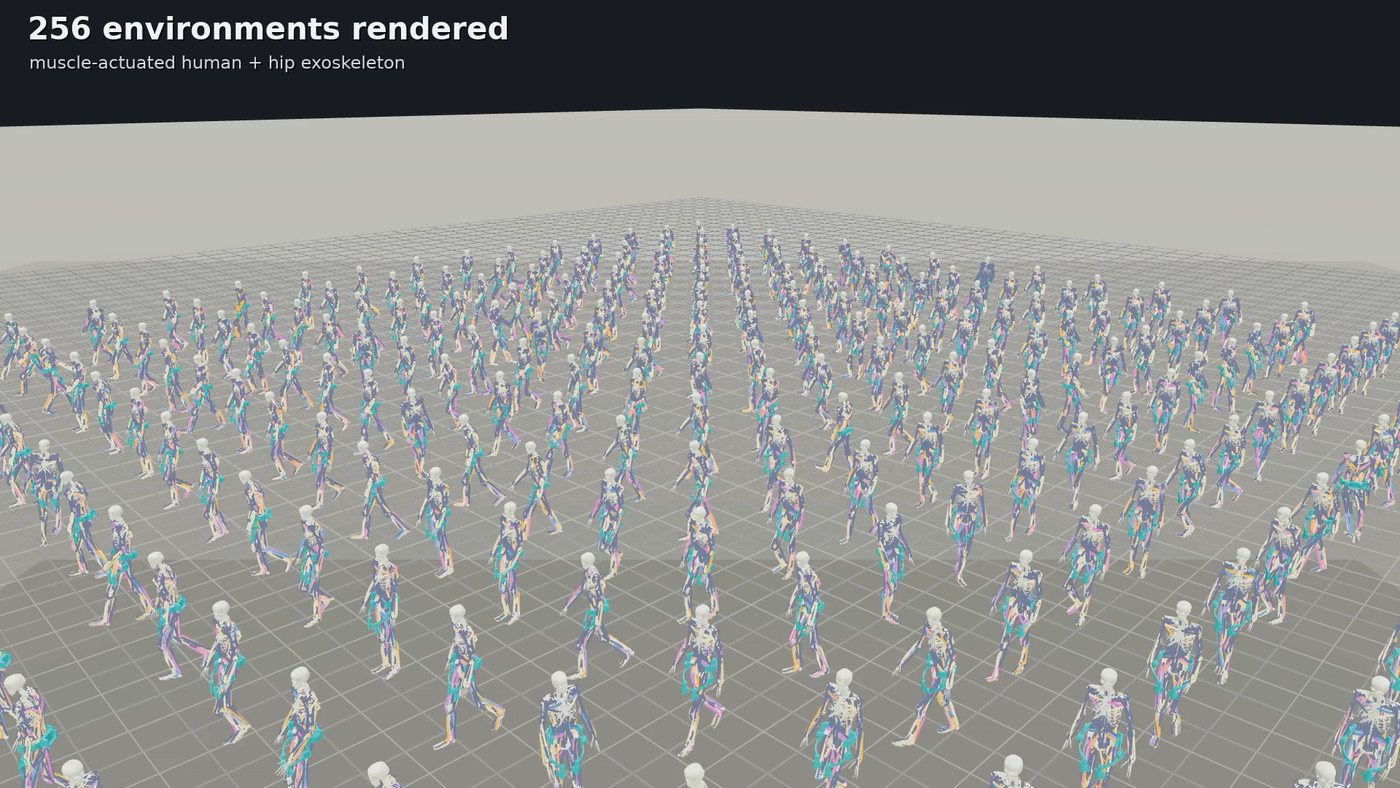
Musculoskeletal simulation usually runs on CPUs, so training a single exoskeleton policy takes hours. We move the musculoskeletal simulation and policy learning onto the GPU, where thousands of simulated humans wearing hip exoskeletons run in parallel. This raises training throughput about 13 times over CPU-based simulation, and once the human controller is prepared, a new assistance policy can be trained in minutes on a single desktop GPU.
Key Publications
- S. Luo, M. Jiang, S. Zhang, J. Zhu, S. Yu, I. Dominguez Silva, T. Wang, E. Rouse, B. Zhou, H. Yuk, X. Zhou, and H. Su, “Experiment-free exoskeleton assistance via learning in simulation,” Nature, vol. 630, no. 8016, pp. 353–359, Jun. 2024. [PDF] [Supplementary Materials] [Editor Perspective]
- S. Luo, G. Androwis, S. Adamovich, E.Nunez, H. Su, and X. Zhou. "Robust walking control of a lower limb rehabilitation exoskeleton coupled with a musculoskeletal model via deep reinforcement learning" J NeuroEngineering Rehabil 20, 34 March 2023. [PDF]
- S. Luo, G. Androwis, S. Adamovich, H. Su, E. Nunez and X. Zhou. "Reinforcement Learning and Control of a Lower Extremity Exoskeleton for Squat Assistance." Frontier Robotics & AI 8:702845. 2021. [PDF] [Video]
See all publications.