Robots
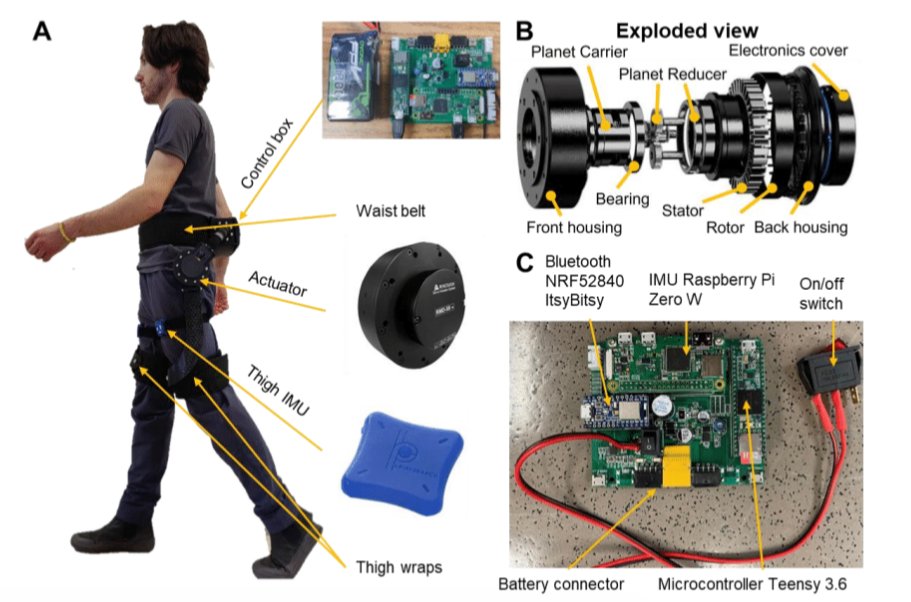
Hip Exoskeleton
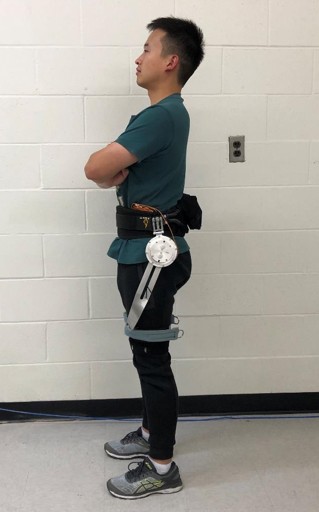
Our design of quasi-direct drive actuation-based exoskeleton demonstrates mechanical versatility for being lightweight (3.2 kg overall mass), compliant (backdrivable) with high torque (36 Nm) and high control bandwidth. The electronic architecture of the exoskeleton facilitated high-level torque control, motor control, sensor signal conditioning, data communication, and power management.
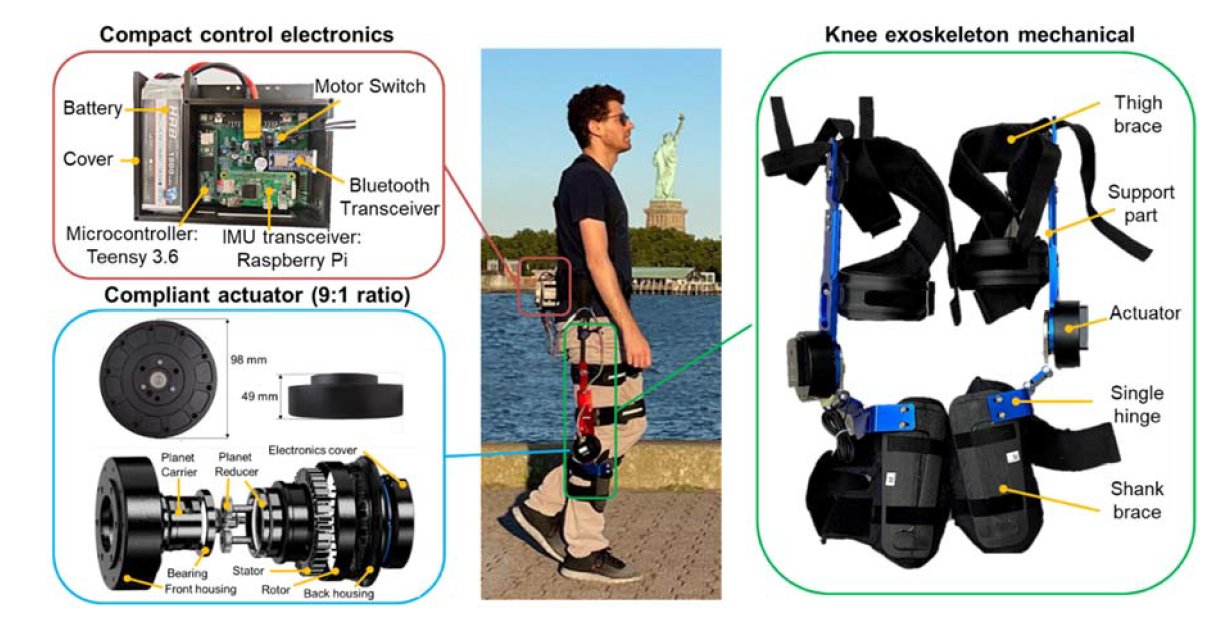
Knee Exoskeleton
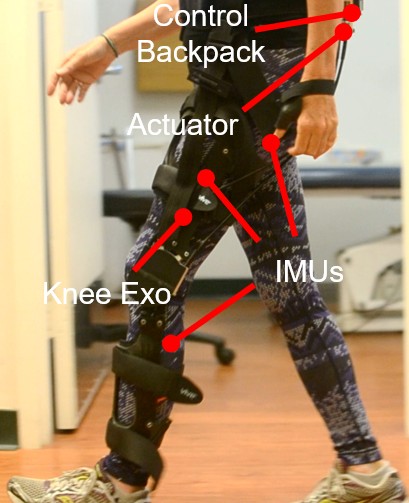
We developed an untethered versatile exoskeleton capable of enhancing productivity via endurance augmentation in multiple activities. This was achieved by a lightweight and compliant robot design, which minimized the energy penalty on the wearer while providing high-torque bidirectional flexion and extension assistance.
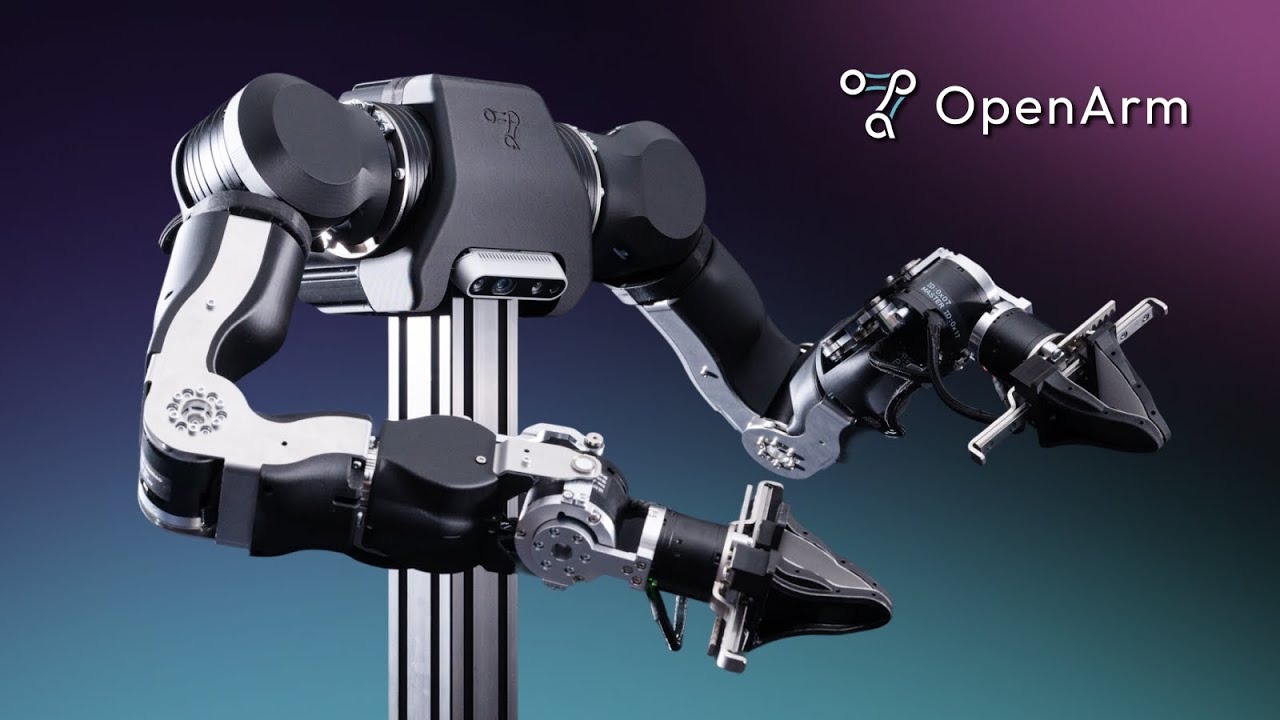
OpenArm Bimanual Robot Arms
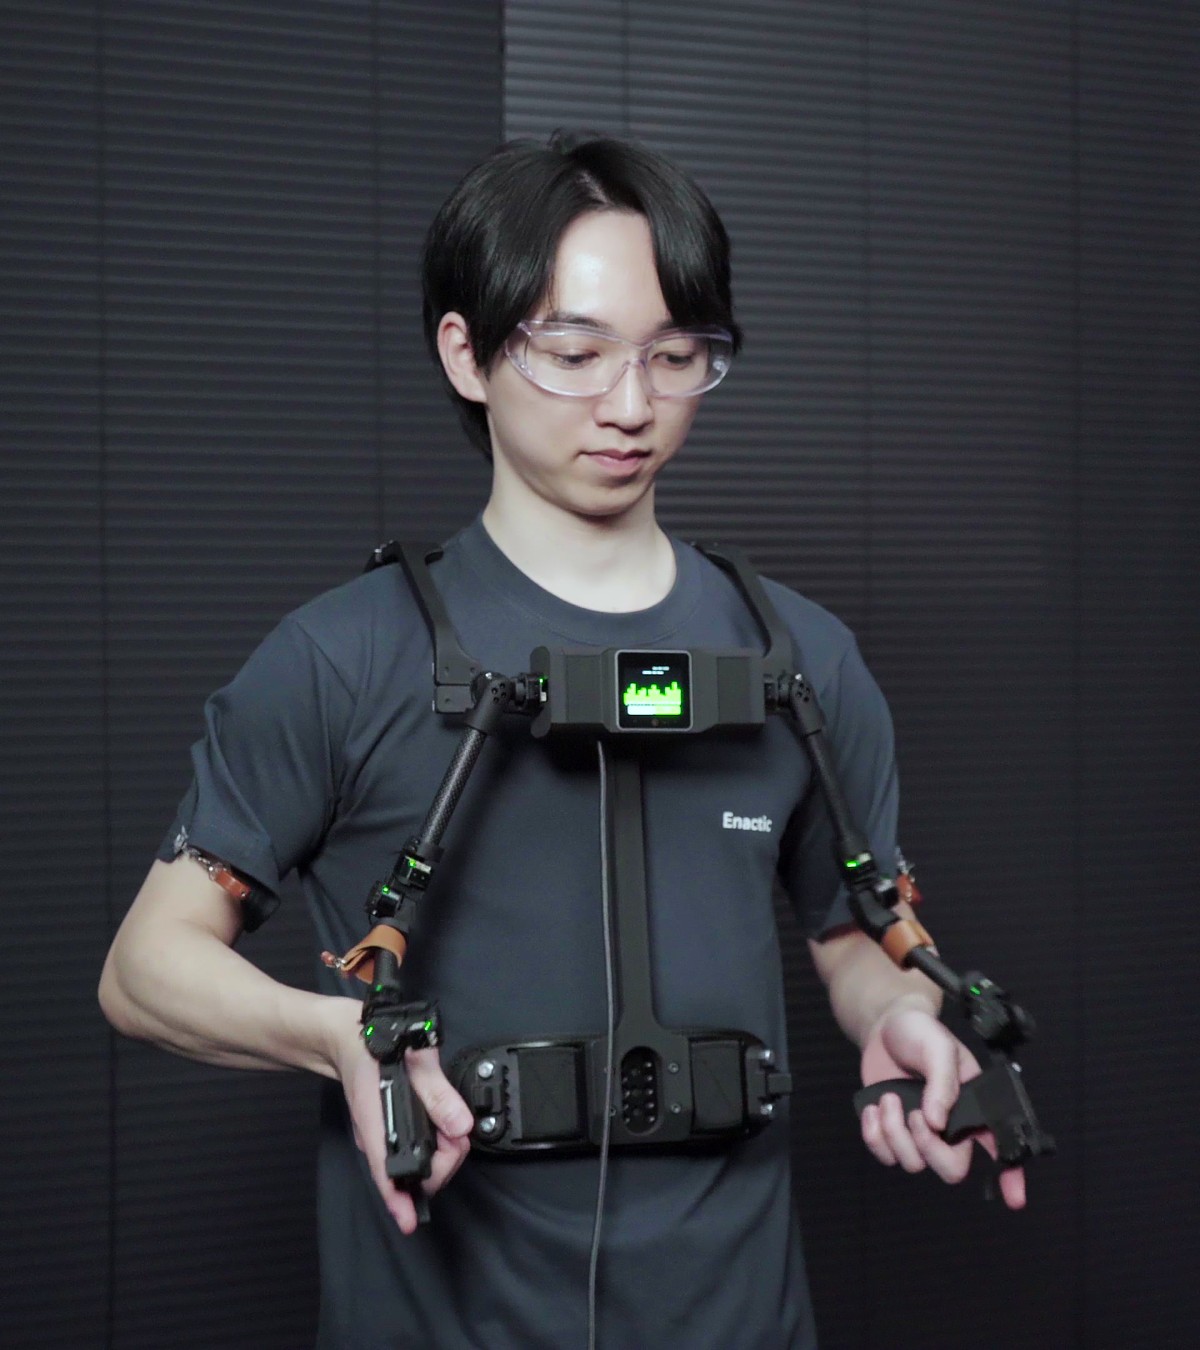
OpenArm is a fully open-source bimanual humanoid robot arm platform developed by Enactic for physical AI research in contact-rich environments. Each arm has 7 degrees of freedom with compliant, backdrivable quasi-direct drive joints and CAN-FD communication. We use OpenArm for research on contact-rich bimanual manipulation, tactile sensing, and force-aware robot learning. For teleoperation, we use the OpenArm KER (Kinematic Equivalent Replica), a lightweight, shoulder-mounted passive arm with the same kinematic structure as OpenArm, to collect high-quality demonstration data over long sessions.
Booster K1 Humanoid Robot
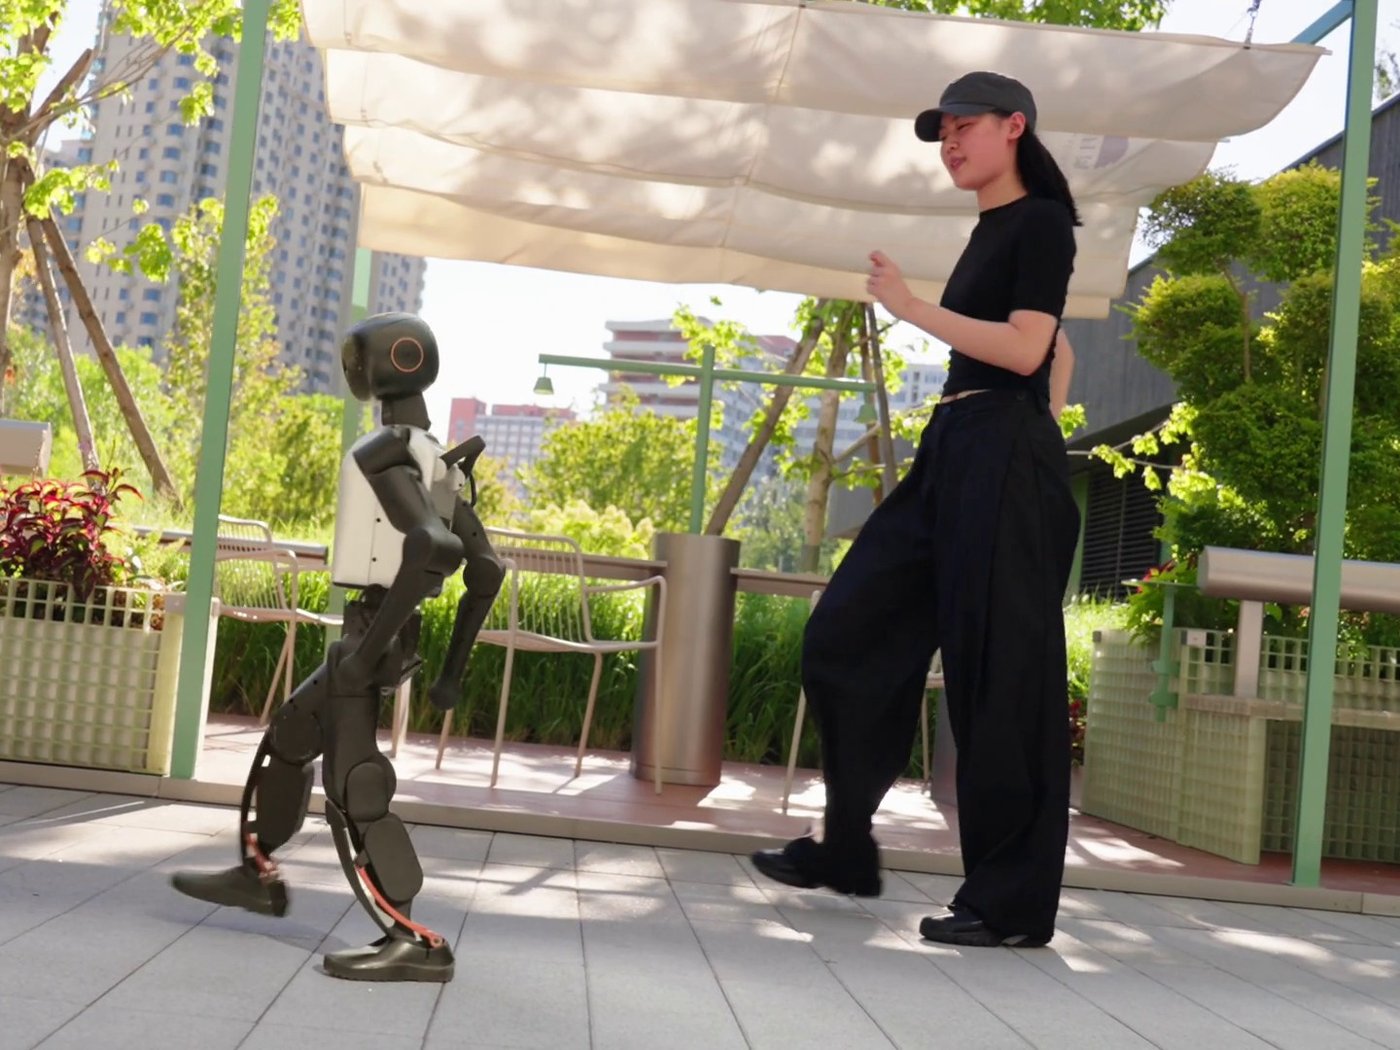
The Booster K1 is a compact humanoid robot developed by Booster Robotics as an embodied AI development platform.
Specs: approximately 95 cm height, 19.5 kg weight, 22 degrees of freedom (6 per leg, 4 per arm, 2 in the head),
and up to 60 Nm peak joint torque.
Knee Prosthesis
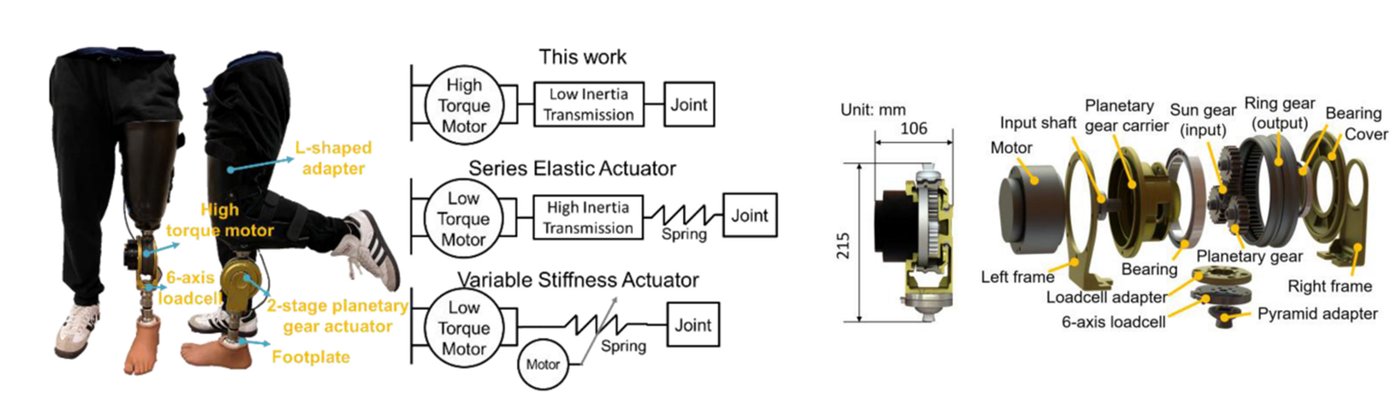
We developed a knee prosthesis using a high torque actuator (built-in 9:1 planetary gear) with a customized 4:1 low-inertia planetary gearbox. Benchtop experiments show that proposed the prosthesis can produce 200 Nm high peak torque, high compliance (2.6 Nm backdrive torque), and high control accuracy (2.7/8.1/1.7 Nm RMS tracking errors for 1.25 m/s walking, 2 m/s running, and 0.25 Hz squatting, that are 5.4%/4.1%/1.4% of desired peak torques).
Facilities and Equipment
The Biomechatronics Lab is a 1,300 sq. ft. research facility equipped with a state-of-the-art motion capture system, humanoid platforms, legged robots, custom surgical robots, wearable exoskeletons, robotic prostheses, advanced physiological measurement devices, high-performance motors, cameras, IMUs, and other cutting-edge tools. The lab is housed within the NYU Center for Robotics and Embodied Intelligence, a 6,800 sq. ft. interdisciplinary space dedicated to advancing robotics and intelligent systems.
Equipment Available
(1) Robot systems
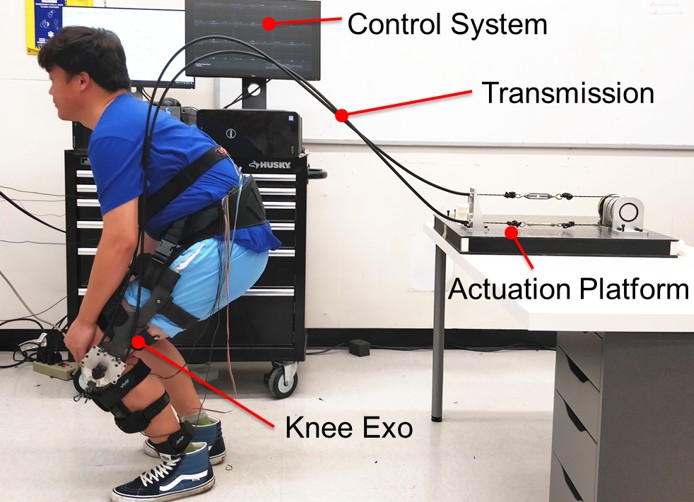
(a) Tethered exoskeleton emulator system: with wearable end-effectors for hip, knee, ankle, and spine joints. Offboard Exoskeleton Test Platform: The platform mainly includes mechanical cable drive actuator platform, electronic sensors, I/O and communication board, and Simulink Desktop Real-Time based real-time control system.
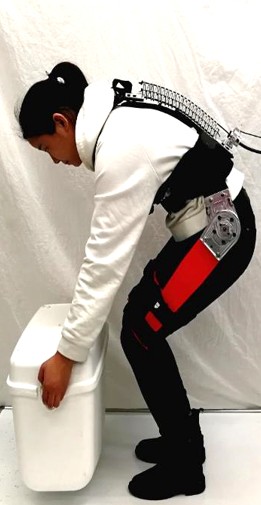
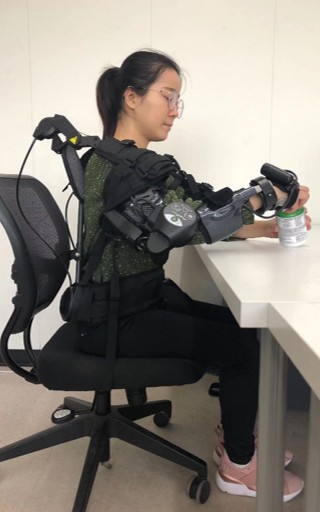
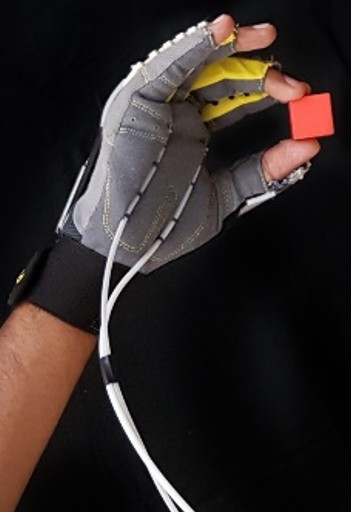
(b) Exoskeletons: Portable soft knee exoskeletons; Portable hip and knee exoskeletons; Powered robotic hand exoskeleton; Bio-inspired back exo, Shoulder exo; Myomo powered elbow exoskeleton.
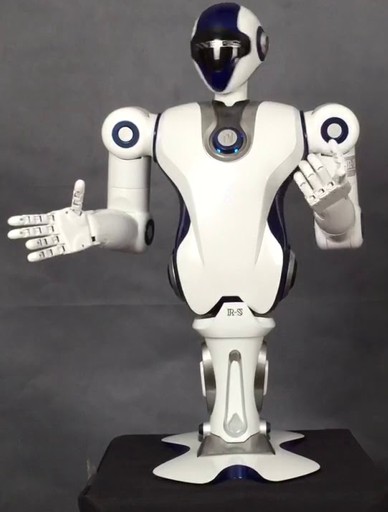
(c) Humanoid robots.
(2) Lab-based Biomechanics Analysis Equipment
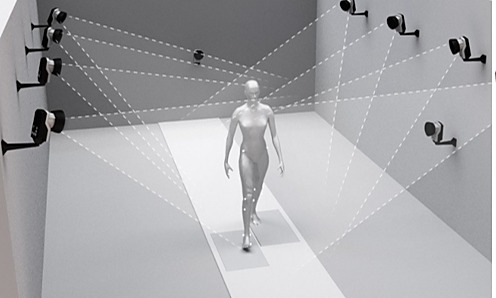
(a) Qualisys video Motion Capture System: 8 cameras.
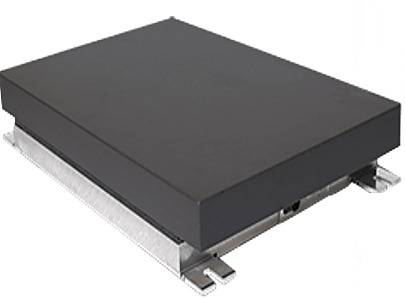
(b) Force plate (Bertec, Inc.).
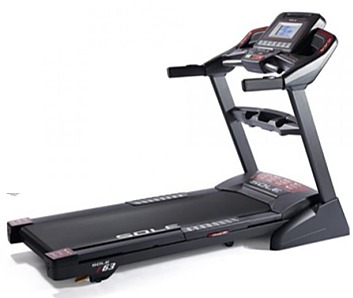
(c) Treadmill: One F63 sole treadmill with adjustable elevation.
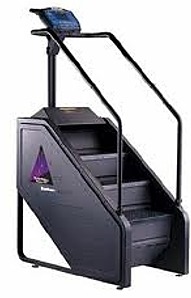
(d) Stepmill: One 7000pt stepmill for stair climbing evaluation.
(e) Biomechanics Analysis Software: AnyBody Technology (musculoskeletal biomechanics modeling software), Biomechanics of Bodies (B.O.B).
(3) Portable Biomechanics Analysis Equipment
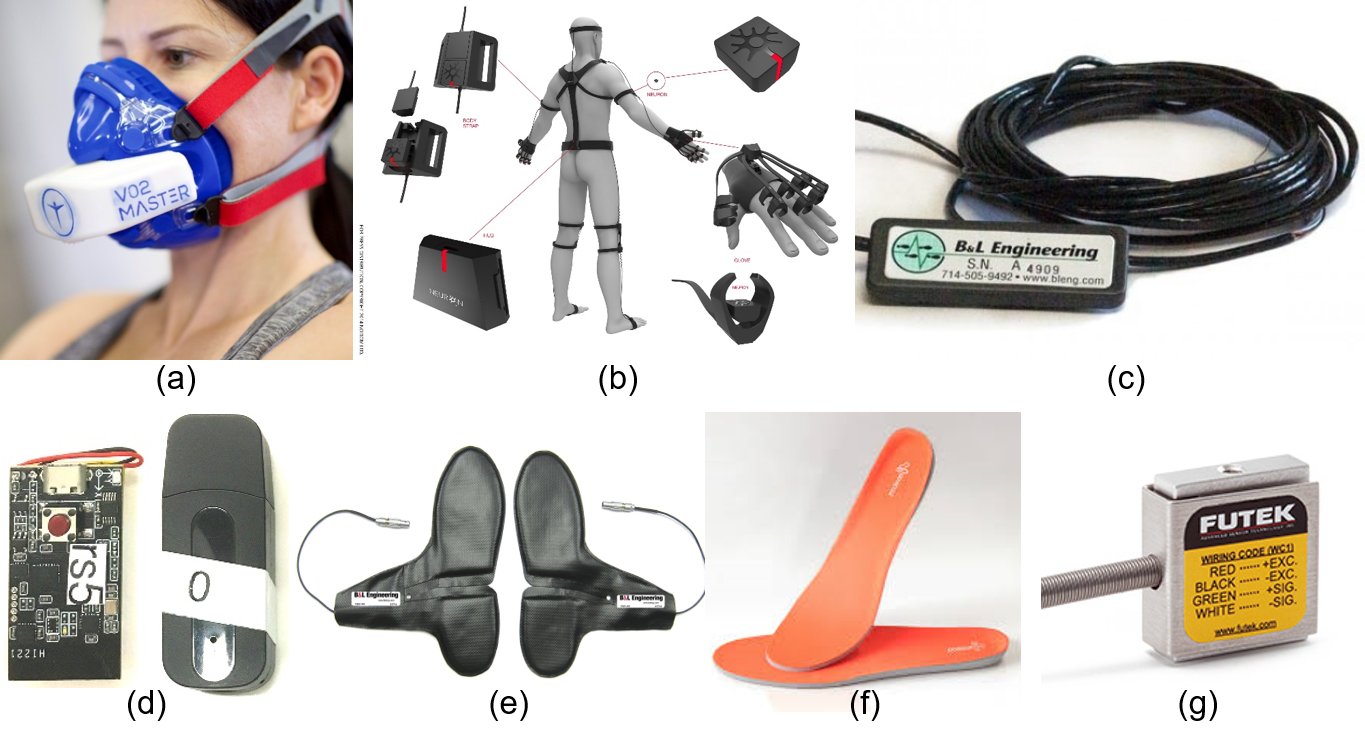
(a) One wearable sensor-based motion capture system (Noitom, Inc.).
(b) Wearable sensors: Customized wireless IMU systems with multiple measurement nodes.
(c) Foot Insole Sensors: One pair of Footswitches insole sensors (B&L Engineering, Inc.), two pair of pressure insole sensors (Podoon, Inc., Moticon, Inc.).
(d) Metabolic Measurement Devices: A portable lightweight human walking metabolic estimation equipment (Goxlabs, Inc.), VO2 mask (Canada).
(e) Electromyography (EMG) Measurement Units: Three customized wireless EMG measurement nodes, eight commercial EMG measurement nodes (B&L engineering, Inc.).
(f) Torque and Force Measurement Sensors: Two loadcells (0~50Nm, Futek, Inc.), four customized loadcells (0~50Nm, 0~100Nm) and one 6-axis loadcell (Sunrise, Inc.), 20 force sensors (0~5kg).
(4) Actuators
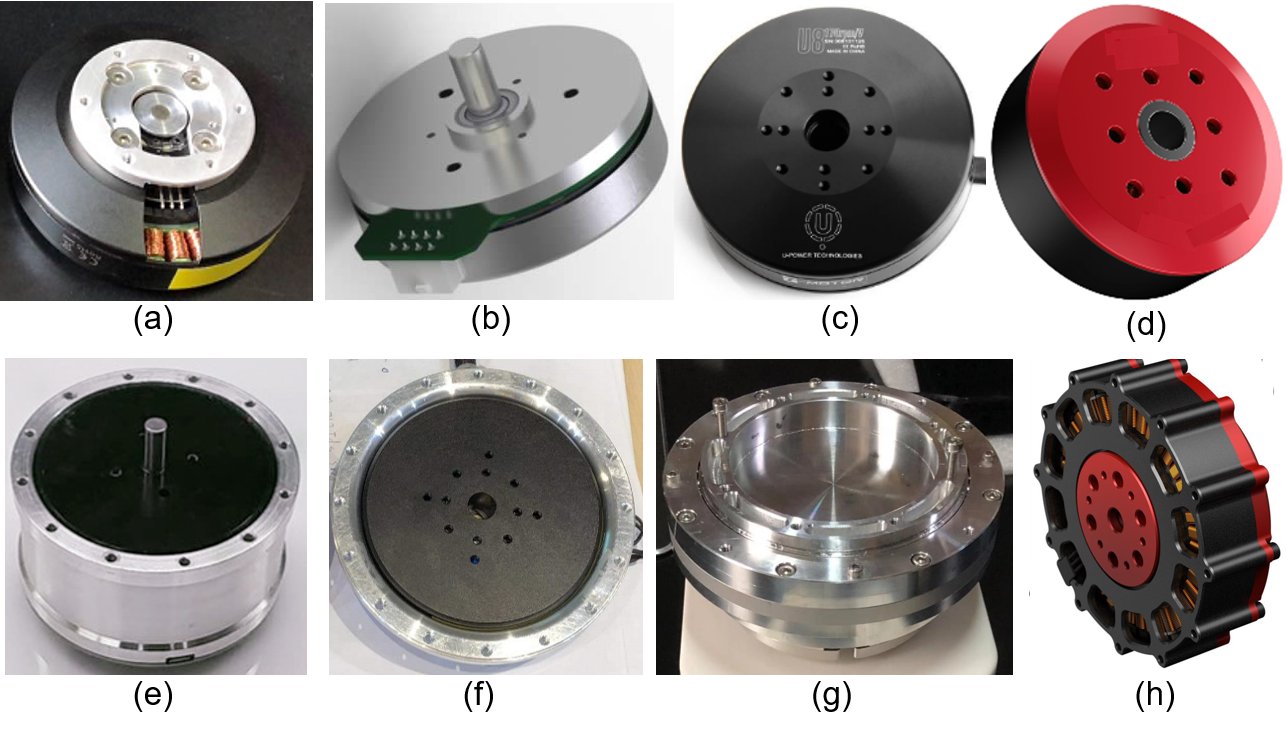
Custom high torque density actuators with motors, gears, motor drivers, magnetic encoders, and embedded controllers, together with commercial motors from Maxon, DJI, T-motor, Yaskawa, and other brands.
(5) Manufacturing and prototyping
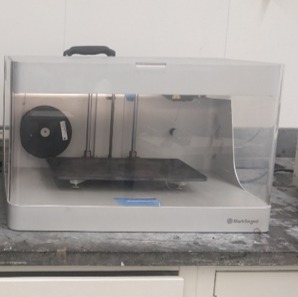
(a) Markforged 3D printer: composites including carbon fiber, Kevlar, Resin, Nylon, Onyx.
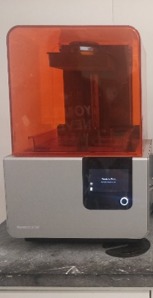
(b) Formlabs 3D Printer: stereolithography.
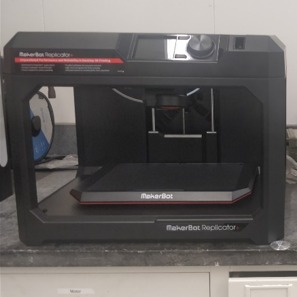
(c) Makerbot: ABS, PLA.
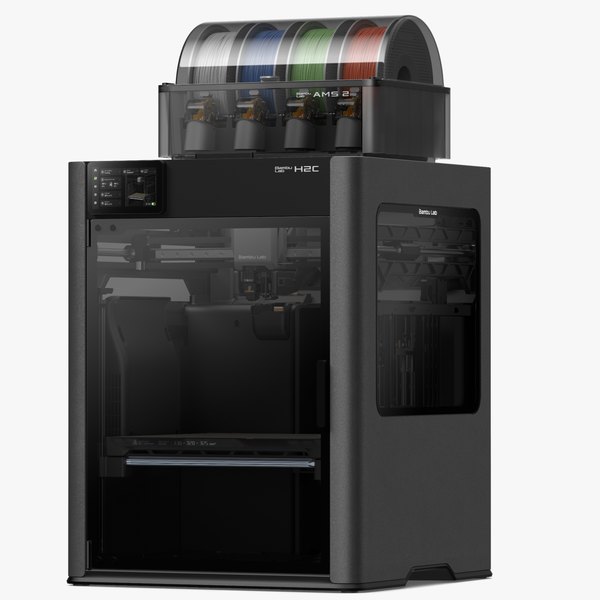
(d) Bambu Lab 3D printers: three state-of-the-art, high-speed multi-material printers for rapid prototyping.
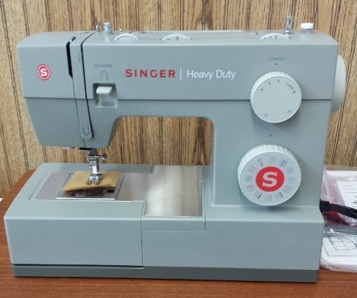
(e) Sewing Machine: Singer Heavy Duty 4452 Sewing Machine.
(f) Prototyping Workshop: Full set of hardware instruments including CNC milling machine, advanced printing machine, laser cutting machine, and advanced circuit board prototyping machine. It can fully support the pneumatic and hydraulic actuator and inflatable exoskeleton manufacturing and testing, customized wearable fiberglass and Silica gel manufacture platform.
(6) Workbench and platforms
(a) Hardware Electronic Platform: Full set of hardware electronic develop the platform, the equipment is including but not limited to, power supply, oscilloscope, signal generator, multimeter, soldering machine, heat gun, Gauss meter, and thermal imager.
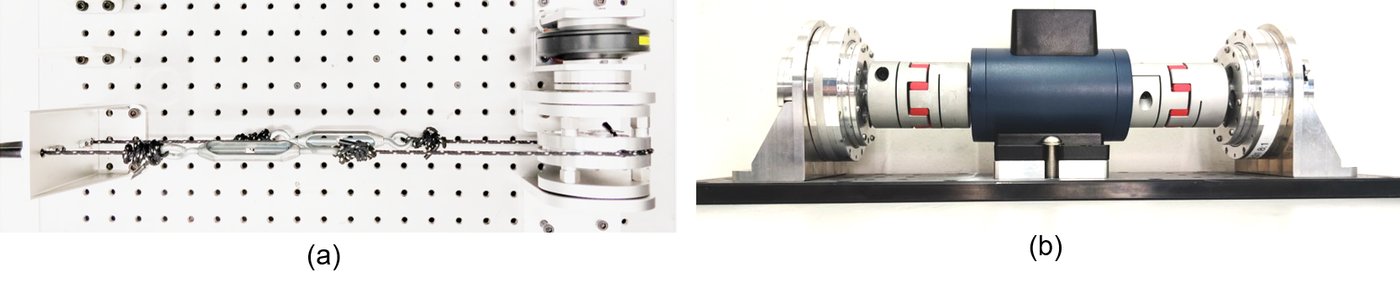
(b) Tethered exoskeleton test platform.
(c) Motor test platform.
(7) Miscellaneous
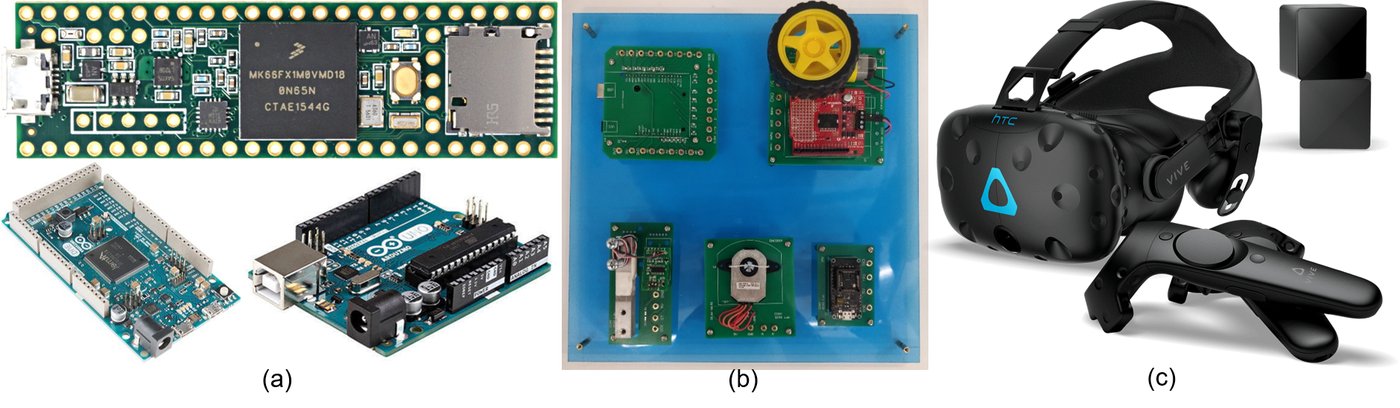
(a) Microcontrollers: Teensy, Arduino, BeagleBone Black, and STM32 boards.
(b) Education Kits: 12 lab-made modular Advanced Mechatronics Education Kits, 2 Festo Bionics4Education education kits.
(c) Virtual Reality System: VIVE VR system (HTC, Inc) with development software and SDK.
(d) Mannequin: Three test mannequins including complete nursing skills mannequin (Keri), Professional Dress Form Female mannequin (Fashion Display) and model mannequin.