
World Models
Force-Aware World Models for Contact-Rich Manipulation
A world model lets a robot imagine the outcome of an action before executing it. We are developing force-aware world models that predict future contact forces along with future camera frames, and output a target motion together with a stiffness for compliant execution. Contact force is estimated from motor current, without a dedicated force/torque sensor.
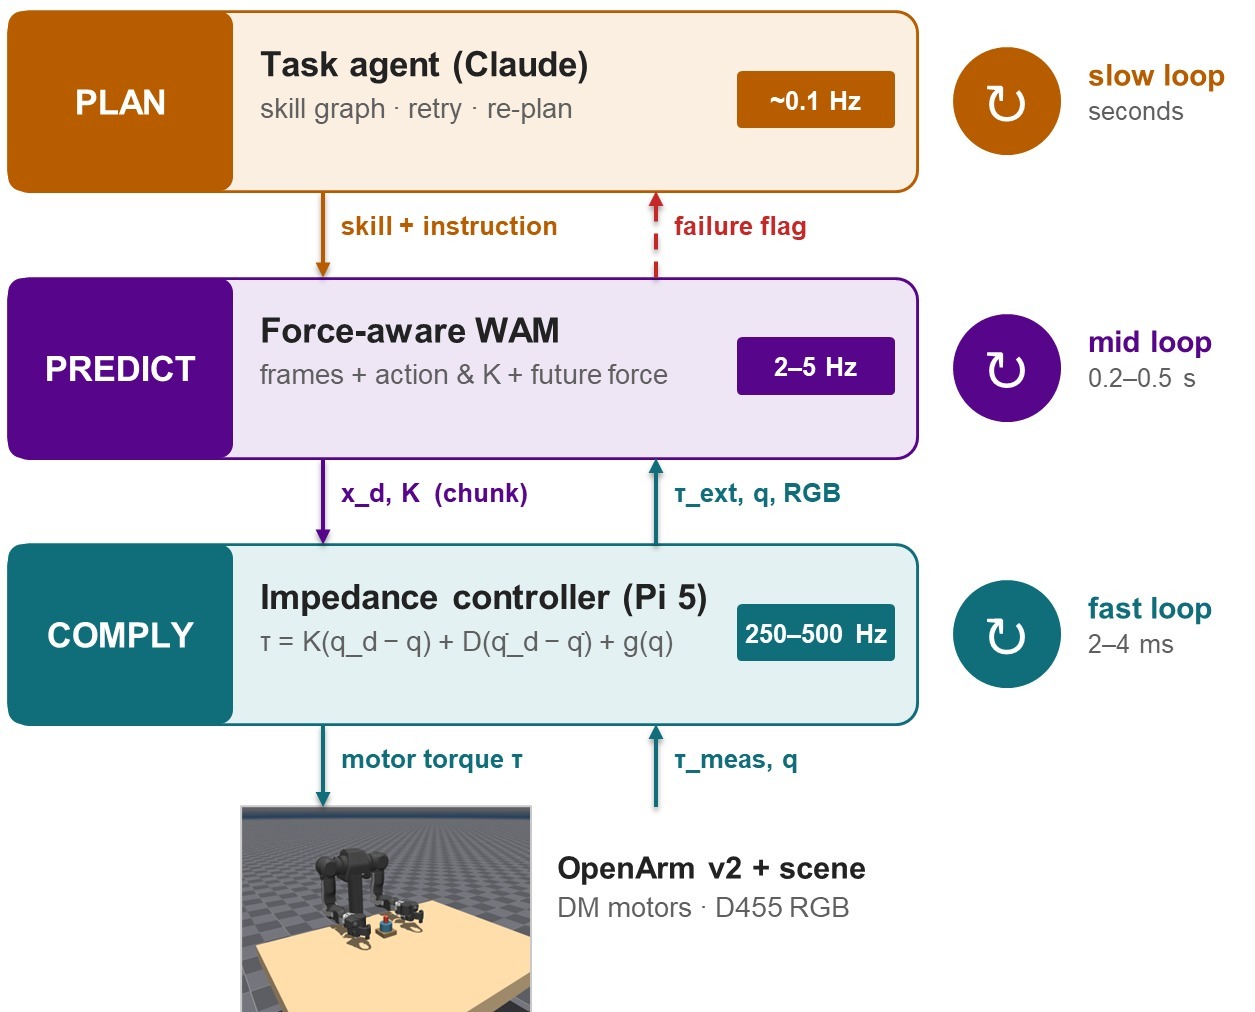
World Models for Neurovascular Intervention
We also build world models for robotic catheter navigation in stroke thrombectomy. Reinforcement learning agents trained in a digital twin of the vasculature, using pseudo X-ray images and virtual haptic feedback, learn to insert and rotate the guidewire and catheters. We distill these task-specific agents into a single world-model agent that performs multiple navigation tasks across different patient vasculatures and generalizes to unseen anatomies. During deployment, the robot can test a candidate motion in the simulator before executing it, checking for vessel-wall contact or instrument buckling, and then act on the next real X-ray frame.
Key Publications
- H. Su, Y. Cui, C. Della Santina, K. Fang, J. Kober, Y. Li, Y. Li, T. Matsubara, M. Pozzi, and B. Zhou, “Embodied AI: Bridging robotics and AI toward real-world applications,” IEEE Robotics & Automation Magazine, vol. 33, no. 1, pp. 6–7, Mar. 2026. [PDF]
- Soleymanzadeh D, Lopez-Sanchez I, Su H, Li Y, Liang X, Zheng M. Towards Generalist Neural Motion Planners for Robotic Manipulators: Challenges and Opportunities. IEEE Transactions on Automation Science and Engineering. 2026 Feb 3. [PDF]
- Y. Gu, G. Shi, F. Shi, I.-C. Chang, Y.-J. Wang, Q. Cheng, Z. Olkin, I. Lopez-Sanchez, Y. Feng, J. Zhang, A. D. Ames, H. Su, and K. Sreenath, “Evolution of humanoid locomotion control,” Science Robotics, vol. 11, no. 117, Aug. 2026. [Full Text] [DOI]
See all publications.