
Open Data and Code
Data, source code, and interactive tools released with our publications. See all publications.
Interactive Tools
Data and Code
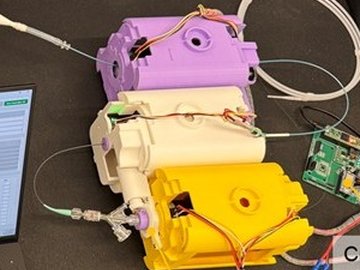
LegoBot
Data and source code for a modular endovascular catheter and guidewire robot for stroke thrombectomy.
W. Gao, N. Srinivasan, D. Piao, Q. Fan, M. Guo, R. Li, P. Patalano, and H. Su, “LegoBot: Modular, compact, device-agnostic robot for endovascular catheter and guidewire manipulation in stroke thrombectomy,” IEEE/ASME Transactions on Mechatronics, vol. 31, no. 4, pp. 4747–4755, Aug. 2026.
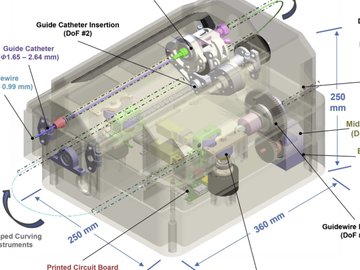
Cardiovascular Catheter Robot
Data and source code for a portable catheter robot for image-guided cardiovascular interventions.
N. T. Kantu, W. Gao, N. Srinivasan, G. D. Buckner, and H. Su, “Portable and versatile catheter robot for image-guided cardiovascular interventions,” IEEE/ASME Transactions on Mechatronics, vol. 30, no. 6, pp. 7985–7994, Dec. 2025.
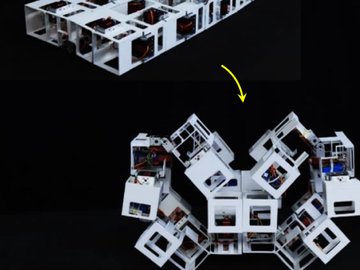
Origami Metastructures
Code for adaptive hierarchical origami-based metastructures.
Y. Li, A. Di Lallo, J. Zhu, Y. Chi, H. Su, and J. Yin, “Adaptive hierarchical origami-based metastructures,” Nature Communications, vol. 15, no. 1, Art. no. 6247, Jul. 2024.